
Latest posts
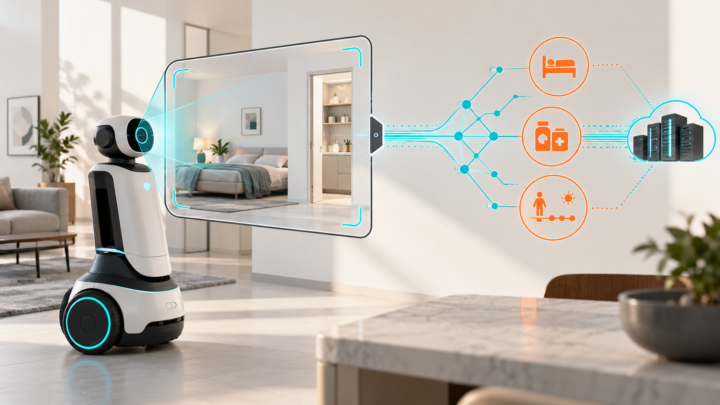
A Robot Can Reveal the Room Without Sharing the Image
Keeping camera streams onboard does not make a robot private. Maps, object geometry and task references can still expose the spaces they describe. A defensible architecture must test every exported representation for utility and residual inference, while treating privacy, cybersecurity and functional safety as separate engineering responsibilities.
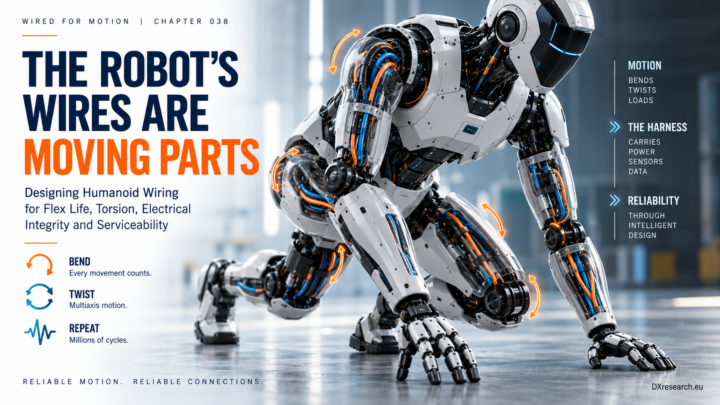
Wires Are Moving Parts
Humanoid wiring moves with every joint, making flex life, torsion, routing, connectors, electrical integrity, diagnostics, and serviceability fundamental reliability requirements.
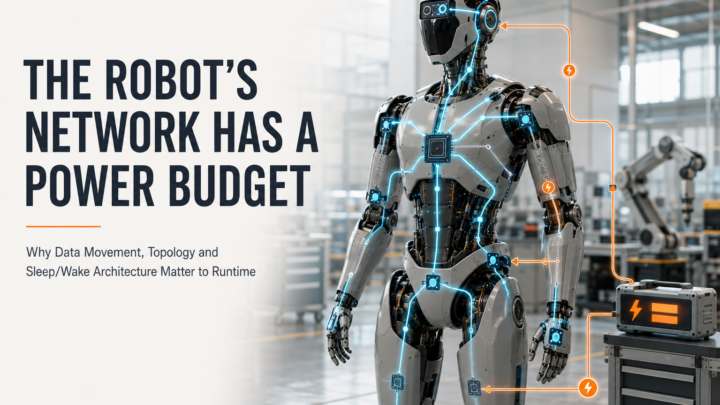
Network Power Budget
Humanoid communication consumes persistent energy; topology, bandwidth, active interfaces, and selective sleep states therefore belong inside the robot runtime budget.
Black Box: Physical AI Must Preserve the Evidence
Robots need protected event evidence linking decisions, commands and physical outcomes, enabling trustworthy reconstruction after failures without permanent workplace surveillance.
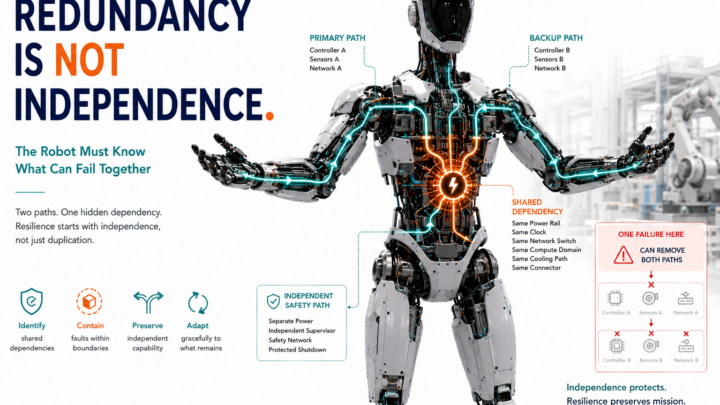
The Robot Must Know What Can Fail Together
Humanoid redundancy matters only when backup functions survive shared failures across power, timing, communication, compute, sensing, cooling, and supervision domains.
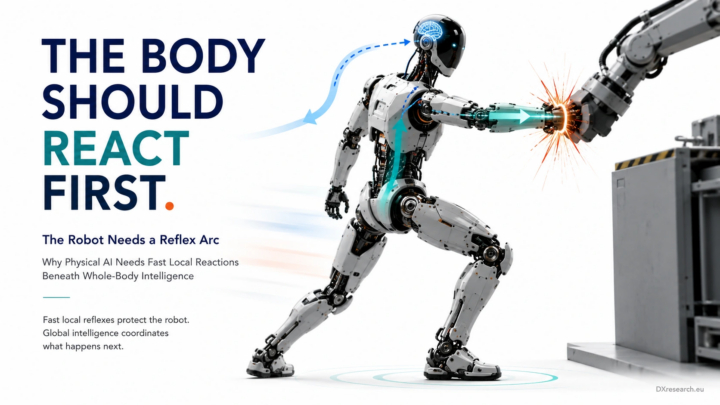
The Reflex Arc
Fast local reflex loops let humanoids mitigate physical disturbances immediately while whole-body intelligence coordinates recovery, safety, balance and task continuity.
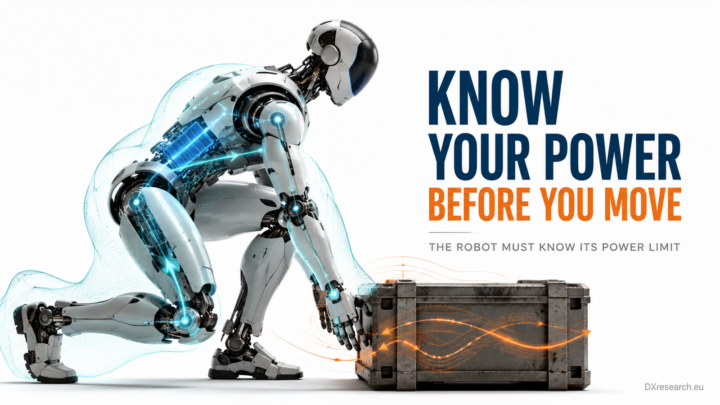
Know Your Power
A robot needs a real-time battery power envelope before motion, because remaining energy alone cannot guarantee the next maneuver safely.
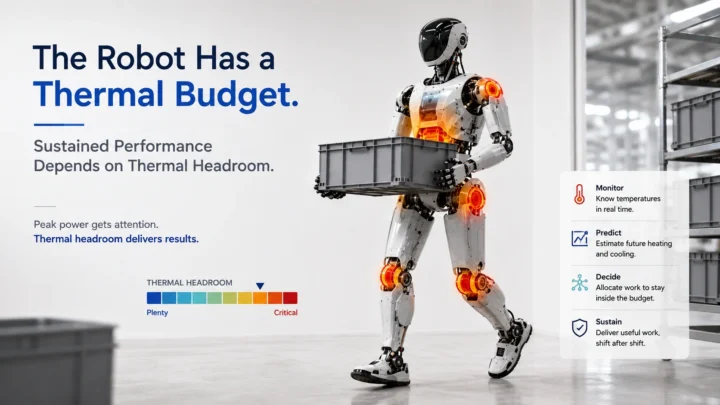
The Robot Has a Thermal Budget
Thermal headroom determines whether humanoid peak performance can become sustained useful work across actuators, compute, batteries and power electronics reliably.
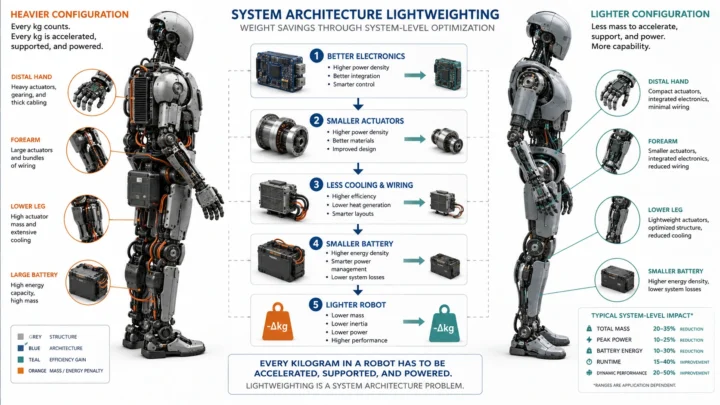
Every Kilogram Has to Move
Robot mass cascades through torque, energy, materials, cooling, wiring and batteries, making lightweighting a system architecture problem for scalable robotics.
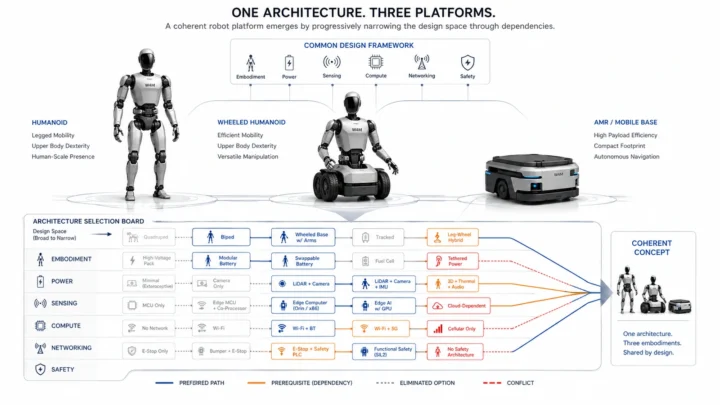
Morphological
Dependency-aware morphological design progressively narrows robot architectures, exposing prerequisites and conflicts before detailed sizing locks expensive subsystem decisions into hardware.
The Robot Needs Its Mother of All Demos
Humanoid robotics needs an integrated demonstration proving that intelligence, motion, power, safety and trust can operate together at industrial scale.
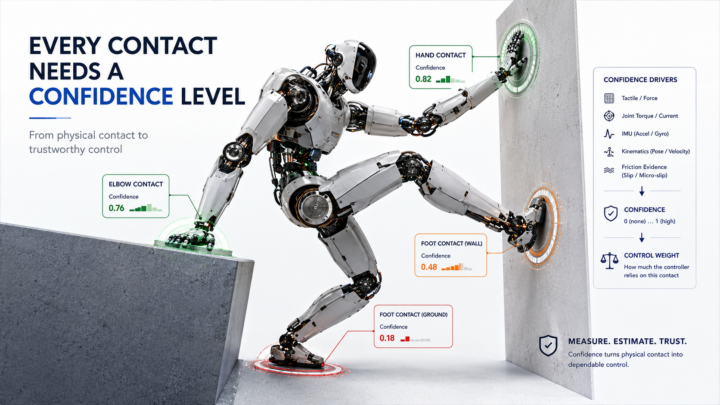
Every Contact Needs a Confidence Level
Reliable humanoid control qualifies every physical contact using synchronized sensor evidence before allocating force, balance authority, or recovery responsibility safely.

