A Robot Must Test the Things It Hopes Never to Use
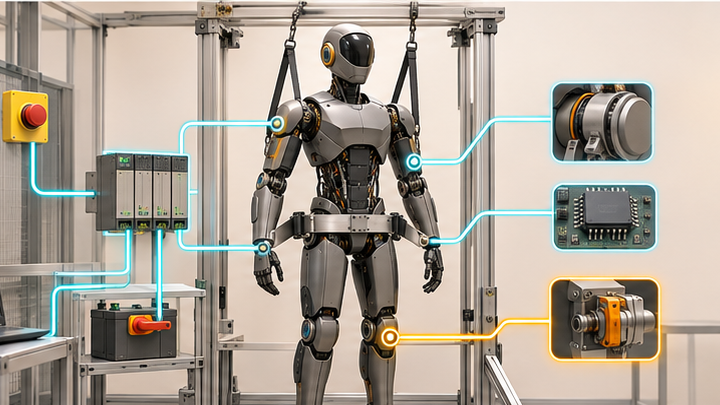
Dormant safety functions can fail silently while robots continue productive work. This white paper examines how humanoid developers can build risk-based proof-test programmes, verify physical outcomes, maintain configuration-aware fleet evidence, and design semiconductor-enabled diagnostics. The resulting assurance depends on independent measurement, secure test authority, disciplined restoration and engineering governance.