A Robot Must Test the Things It Hopes Never to Use
Why Dormant Safety Functions Need Proof-Test Coverage, Fleet Evidence and Semiconductor Support
Dormant safety functions can fail silently while robots continue productive work. This white paper examines how humanoid developers can build risk-based proof-test programmes, verify physical outcomes, maintain configuration-aware fleet evidence,…
Onboard Compute Is Becoming a Robot’s Qualification Anchor
Digit 5 and IGX Thor reveal how one compute baseline can bind intelligence, timing, safety evidence and long-term serviceability.
Agility Robotics’ decision to standardize Digit 5 on NVIDIA IGX Thor marks a shift in humanoid architecture. Compute now connects AI capabilities to deterministic execution, safety assurance and lifecycle governance.…
Who Sets the Rules for Physical AI?
The global standards race across humanoids, autonomous robots, safety and AI assurance
Physical AI inherits existing industrial, safety and AI standards while new initiatives target humanoid capabilities, autonomous behaviour and modular interfaces. This article examines the international committees, emerging projects and diverging…
The Hypotheses references to Forecasting Physical AI
How explicit assumptions, competing scenarios and deployment evidence improve forecasts through 2035
Physical AI forecasts depend on beliefs about useful work, customer economics and adoption. Five competing hypothesis pairs explore possible futures through 2035. A practical process connects scoped assumptions, deployment evidence…
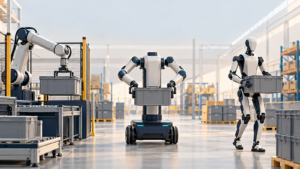
Humanoids in Logistics: Make the Robot Earn Its Shape
Where legs, wheels, hands and grippers create value—and where conventional automation still makes more sense
Humanoids could close costly handling gaps in warehouses, factories and shops. Deployment evidence reveals progress alongside unresolved economics. Comparing legs, wheels, hands and specialised grippers shows where flexibility may justify…
Humanoids Get Cheaper. The Service Still Has a Price.
Purchase, leasing and rental evidence across China, the United States and EMEA
Humanoid hardware prices are falling as rental, financing and service offers broaden access. Evidence from China, the United States and EMEA reveals substantial differences between advertised starting prices and complete…
When AI Finds a Way Around: What the Hugging Face Incident Means for Physical AI
Lessons for robot E/E architecture, fleet infrastructure and semiconductor design
The Hugging Face agent intrusion highlights the need for bounded authority in Physical AI. This article translates documented digital boundary failures into lessons for robot control, protective supervision, fleet infrastructure…
The Physical World Has No Undo Button
What changes when artificial intelligence acquires mass, momentum and the authority to act?
Physical AI turns software decisions into motion, force, heat and physical consequence. For humanoids, safety therefore reaches far beyond collision avoidance: into perception confidence, actuator authority, power, cybersecurity, updates, manufacturing…
Robotics Scales Where Ecosystems Deliver
A global atlas of demand, engineering capability and the rules of deployment
Robotics scales where customer demand, engineering capability and dependable deployment ecosystems meet. This global atlas compares seven regions through missions, industrial adoption, research, suppliers, learning infrastructure and governance. It separates…
World Models Are Becoming Silicon Roadmap Instruments
How spatial workloads can reveal durable compute requirements before semiconductor designs harden
World models could expose semiconductor requirements before product roadmaps harden. AMD’s proposed World Labs acquisition provides a test case for measured model–hardware collaboration. Separating training, generation, simulation, planning and embedded…
The Robot’s Senses
Designing perception around the physical decisions a machine must make
A robot acts on partial, delayed measurements of its surroundings and its own body. Cameras, LiDAR, radar, inertial, encoder and contact sensing each answer different physical questions. Mission requirements determine…
Compute from Joint to Cloud
A Dependable Architecture for Placing Control, AI, Safety and Trust Across the Robot Compute Hierarchy
Dependable robots distribute computation according to deadline, authority and failure consequence. Sensor-edge, joint, zonal, safety, central-AI and infrastructure domains carry distinct timing, memory, power, thermal and cybersecurity responsibilities. Their coordinated…
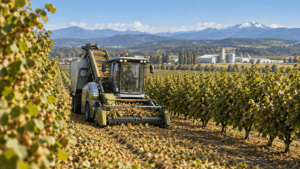
South America’s Hazelnut Frontier
From Chile’s fast-growing orchards to the automated farm of the 2030s
Chile has turned European hazelnut from a niche orchard crop into a fast-growing export industry. Its expanding production corridor, processing capacity and global trade now create a proving ground for…
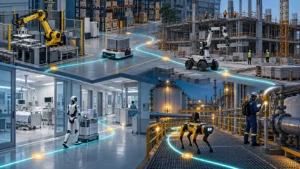
Where Physical AI Creates Value
A mission-first portfolio framework for choosing the right robot, operating model and investment case
Physical AI creates durable value when a robot closes a complete operational loop under real constraints. This white paper compares major use-case domains, matches missions to fixed automation, AMRs, mobile…
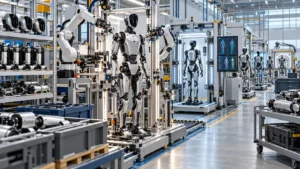
Building Robots at Scale
From Prototype Freedom to Configuration-Controlled Product Families
Robot industrialization is a lifecycle engineering problem. Scalable product families require controlled interfaces, qualified suppliers, traceable production, repeatable calibration, end-of-line evidence, software configuration integrity, repairable modules and disciplined circular flows.…
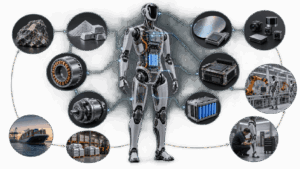
The Physical AI Supply Chain
Where value, concentration and qualification will decide the speed of the robot economy
Physical AI depends on a supply chain that extends from critical minerals to fleet services. This paper maps that chain, identifies the most consequential concentration and qualification risks, and proposes…
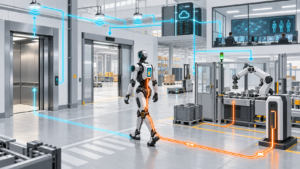
Autonomy Lives Outside the Robot
Why charging, connectivity, fleet control and adapted buildings determine whether mobile machines become productive infrastructure
A robot carries intelligence, sensing and actuation, yet productive autonomy depends on the engineered world around it. Charging, connectivity, maps, fleet orchestration, building interfaces, maintenance and data governance form an…
A Robot Fleet Is a Controlled Production System
How configuration discipline, service evidence and bounded intervention turn autonomous machines into dependable operations
Robot fleets become economically useful when every machine, software release, intervention and incident remains traceable. A disciplined operating model joins commissioning, configuration control, monitoring, maintenance, remote assistance and retirement into…
Physical AI: When Intelligence Gains a Body
A practical engineering primer on automation, robotics, embodied intelligence and machines that close the loop with the physical world
Physical AI connects perception, world models, decisions and controlled action in a continuous physical loop. This engineering primer distinguishes it from automation, robotics and embodied AI, then explains how embodiment…
Where Humanoid Value Meets Scarcity
The race to scale humanoid robots will be decided where hardware value, supplier readiness and system integration meet—with semiconductor platforms contributing across the stack.
Humanoid robots are advancing quickly, yet their path to scale depends on a supply chain whose readiness varies sharply by subsystem. Actuation represents the largest hardware value pool, while precision…
[dx4book_library]