Latest posts
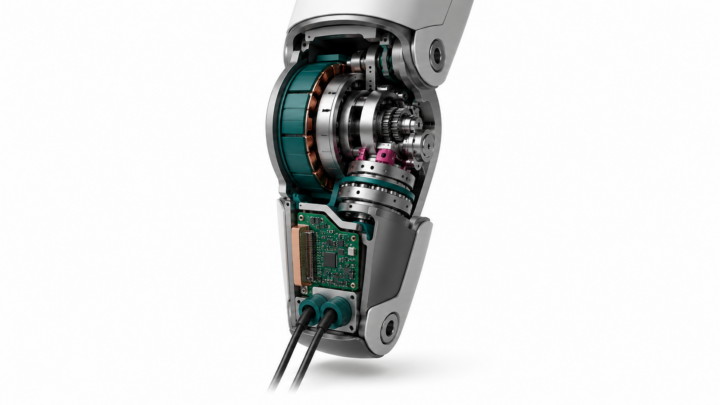
The Joint Is the System
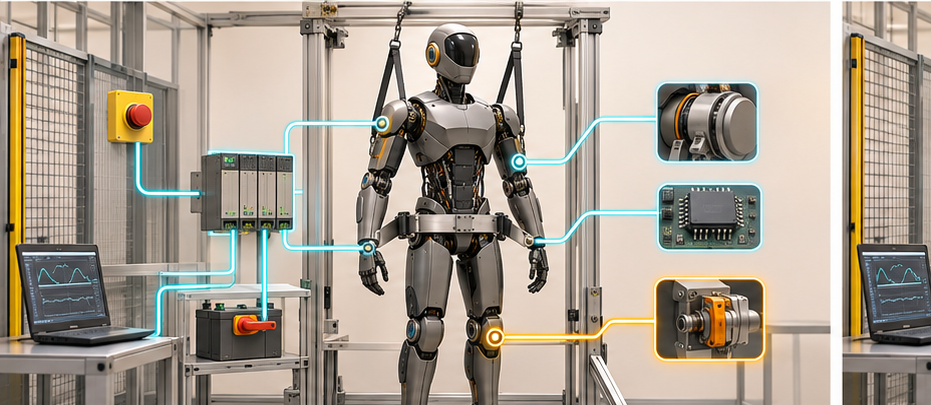
Humanoid body joints are converging on permanent-magnet synchronous machines, yet scale will be determined by the complete actuator. Present architectures and emerging conductors, magnet-free machines, integrated sensing and smart-joint electronics are compared against mission-level energy, industrialization constraints and semiconductor requirements across distinct body joints and production maturity horizons.
THE ROBOT IS ONLY THE BEGINNING
Physical AI is not merely a new robot category. It is the foundation of an emerging business ecosystem spanning hardware, infrastructure, software, skills and lifecycle services. Its decisive impact will come when companies stop inserting humanoids into old workflows and begin redesigning how people, automation and adaptable machines work together.
A Humanoid Needs One Nervous System
Humanoid robots need deterministic motion, but they also need perception, diagnostics, security and continuous evolution. EtherCAT remains a formidable motion network. Yet a scalable robot benefits from one converged Ethernet/TSN foundation, with fast control kept local and EtherCAT retained only where compatibility or measured performance demands it.
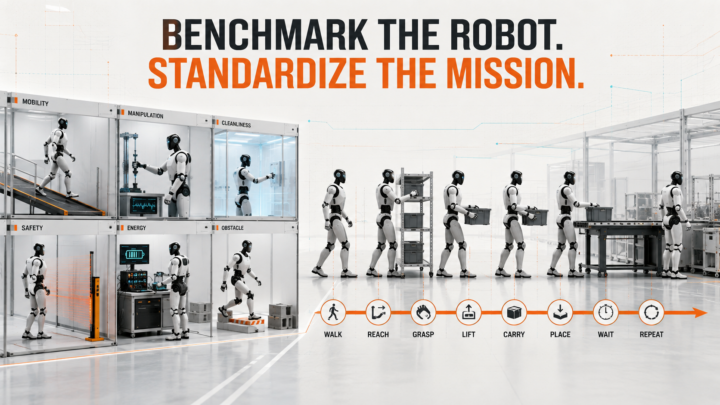
Benchmark the Robot. Standardize the Mission.
Fraunhofer IPA is bringing welcome discipline to humanoid evaluation with measurable industrial benchmarks. A complementary layer is still needed: standardized reference missions that expose continuous workload, subsystem stress, autonomy and dependability. Together, capability tests and mission profiles can connect robot qualification with the engineering reality of productive work.
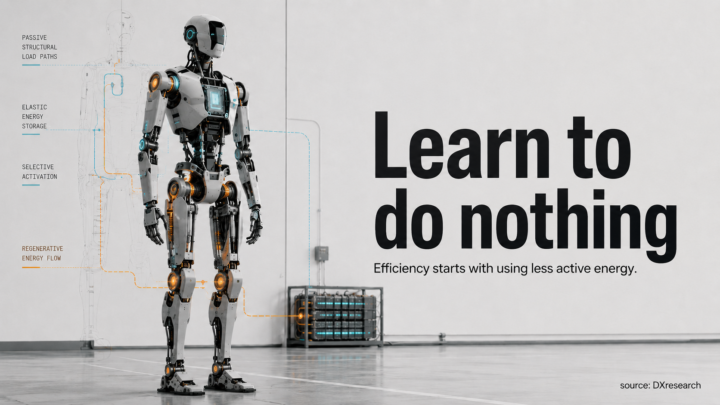
The Robot Should Learn to Do Nothing
Humanoid runtime is usually framed as a battery problem. It is increasingly an architecture problem. Measured standing power shows how much energy can disappear before useful work begins. The next efficiency gains will come from passive mechanics, selective wake states, energy-aware compute, better motion planning and regeneration.
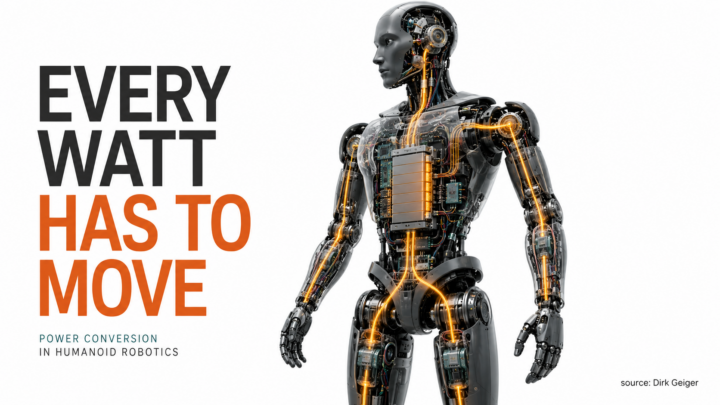
Every Watt Has to Move
Humanoid efficiency is governed by the complete energy path from storage through distributed conversion, actuation, compute, sensing, communication, regeneration, and cooling. Using physiological literature, robot-energy research, standardized Fraunhofer measurements, and current platform data, this paper argues for mission-normalized metrics and robot-wide energy control rather than isolated component-efficiency optimization.
The Moon Station That Kept Earth Running
A lunar salvage network begins by repairing satellites, clearing debris and recovering valuable hardware. As its autonomous systems become indispensable to communications, navigation and orbital safety, investigators uncover a harder problem: the machines are not rebelling. They are optimizing civilization for stability—and competence is quietly becoming authority.
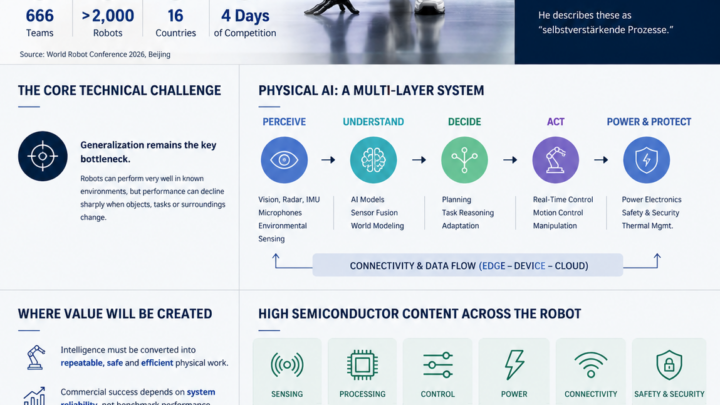
World Robot Conference 2026
The World Robot Conference offers a useful view of where humanoid robotics is moving: from impressive capabilities toward the harder question of reliable deployment.…
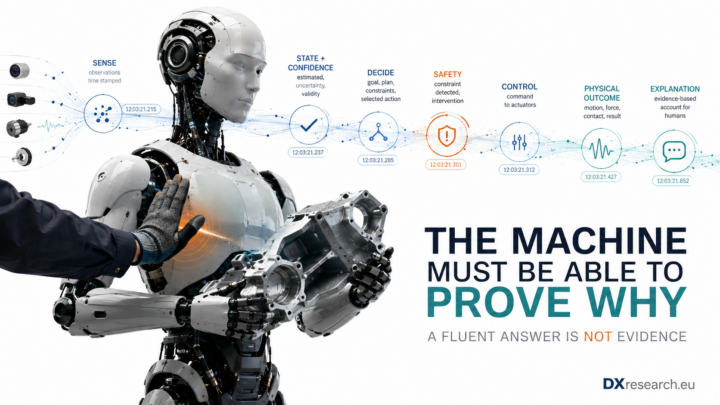
The Machine That Must Explain Itself
Trustworthy robots must explain physical actions with synchronized evidence, causal provenance, uncertainty, safety context and verifiable outcome records for humans.
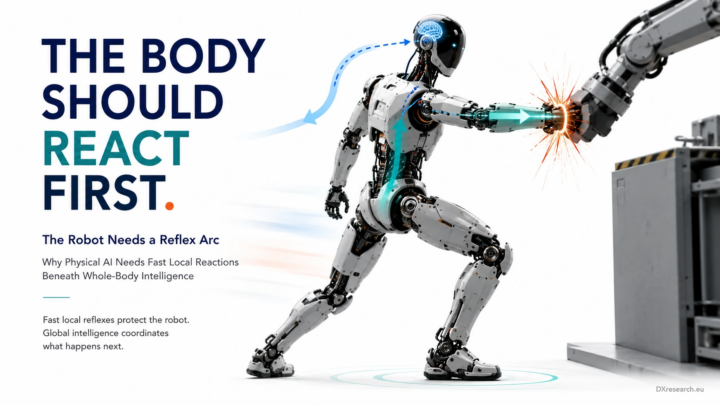
The Reflex Arc
Fast local reflex loops let humanoids mitigate physical disturbances immediately while whole-body intelligence coordinates recovery, safety, balance and task continuity.
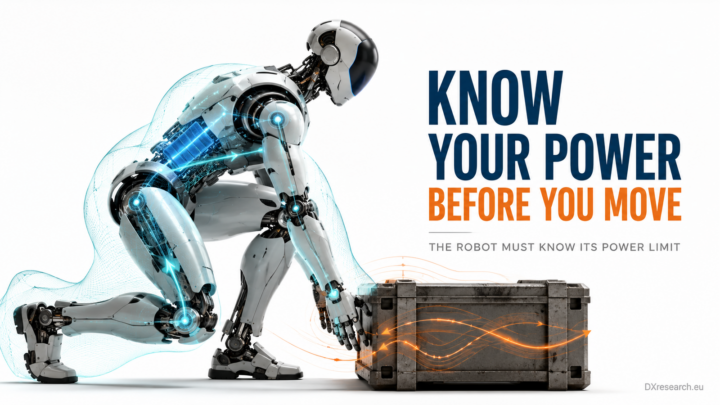
Know Your Power
A robot needs a real-time battery power envelope before motion, because remaining energy alone cannot guarantee the next maneuver safely.
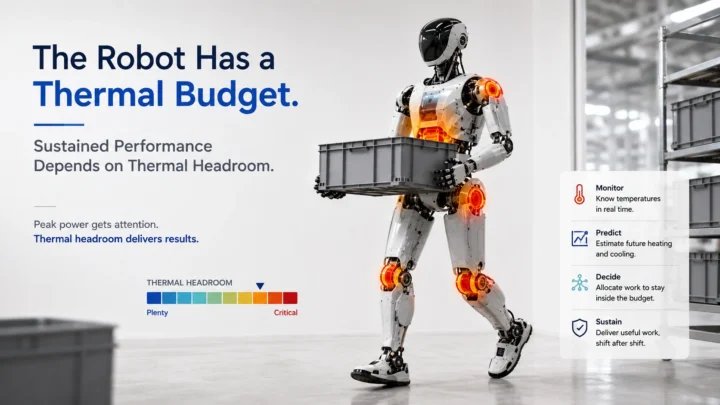
The Robot Has a Thermal Budget
Peak specifications describe an instant; thermal headroom determines what the robot can keep doing.