Latest posts
The Robot Needs Its Mother of All Demos
Humanoid robotics needs an integrated demonstration proving that intelligence, motion, power, safety and trust can operate together at industrial scale.
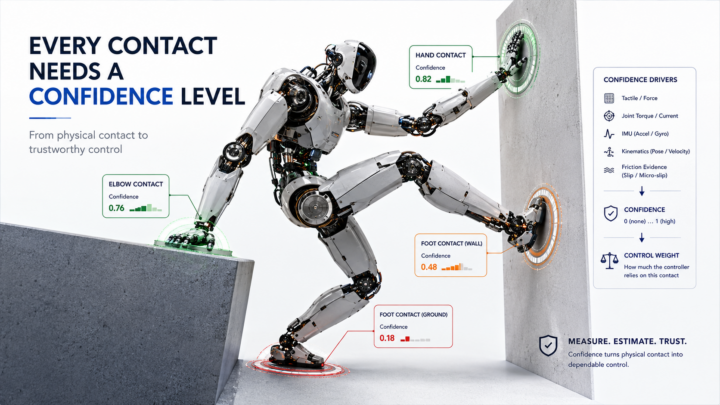
Every Contact Needs a Confidence Level
Reliable humanoid control qualifies every physical contact using synchronized sensor evidence before allocating force, balance authority, or recovery responsibility safely.
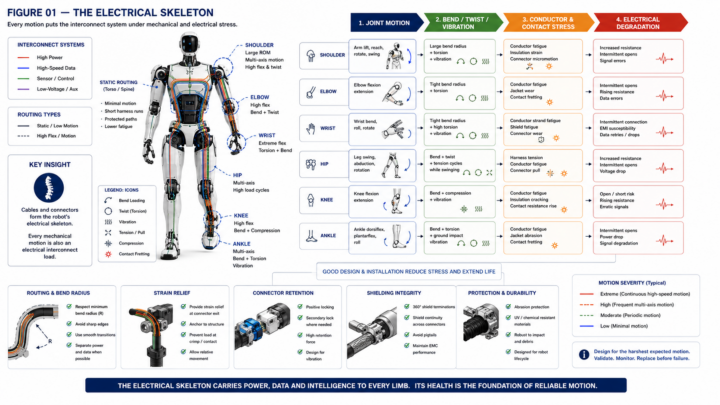
The Robot Has an Electrical Skeleton
Humanoid cables and connectors must remain trustworthy through repeated bending, twisting, vibration and wear across millions of demanding body movements.
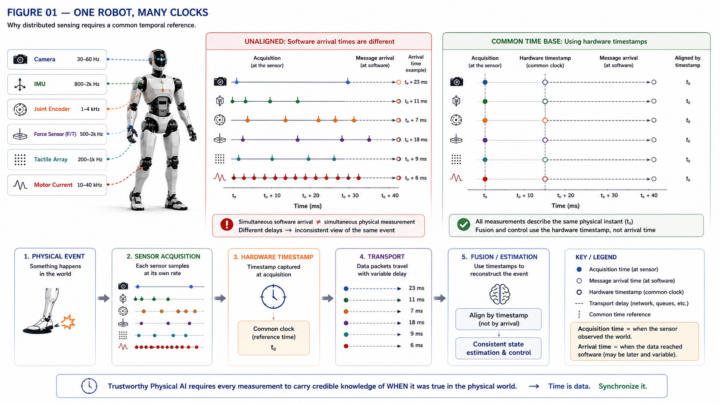
The Robot Needs a Common Clock
Humanoid control needs synchronized timestamps so distributed sensors, actuators, estimators and safety logic describe the same physical moment reliably together.
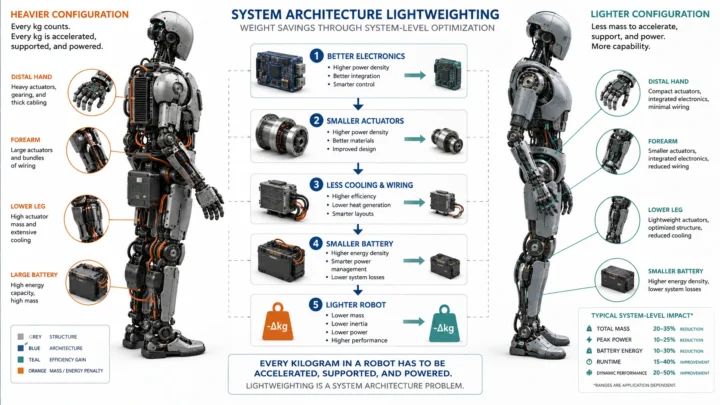
Every Kilogram Has to Move
Robot mass cascades through torque, energy, materials, cooling, wiring and batteries, making lightweighting a system architecture problem for scalable robotics.
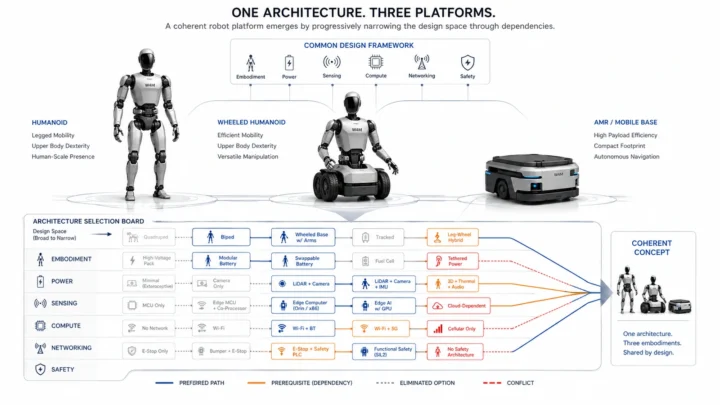
Morphological
Dependency-aware morphological design progressively narrows robot architectures, exposing prerequisites and conflicts before detailed sizing locks expensive subsystem decisions into hardware.
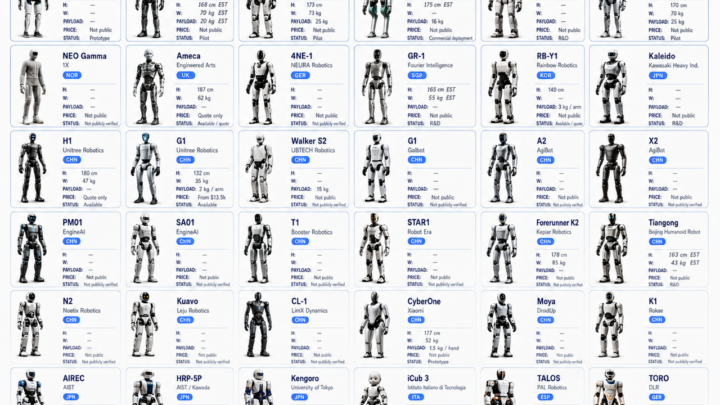
Humanoids 2026
Apptronik Apollo launch — 173 cm, 73 kg, 25 kg payload. Agility Robotics Digit — 16 kg carrying capacity and four-hour battery claim; height is retained…
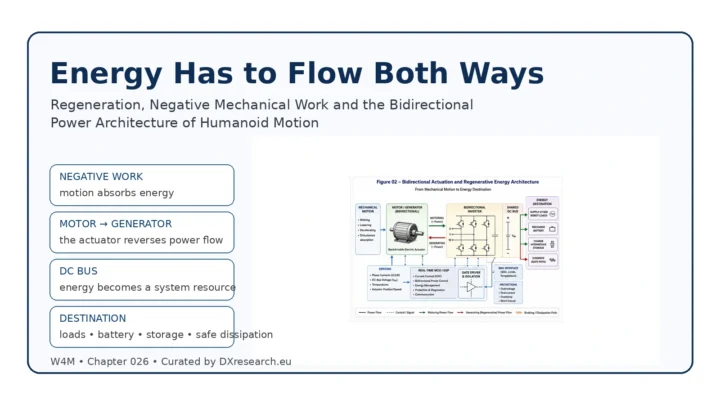
Energy Has to Flow Both Ways
Humanoid efficiency depends on capturing, routing and absorbing negative mechanical work through coordinated bidirectional actuation, power electronics and energy control.
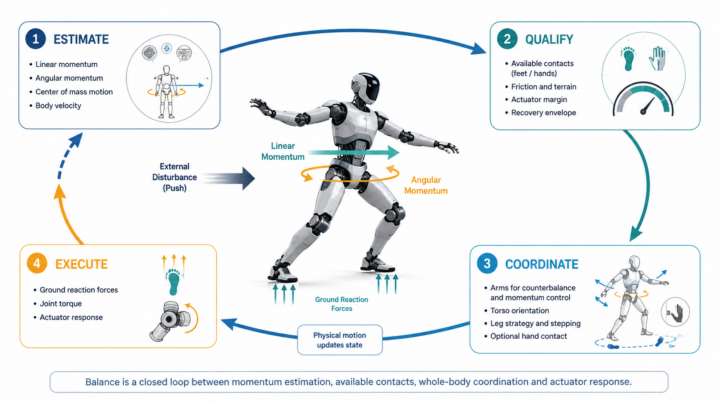
Balance Is Momentum Management
Humanoid balance depends on managing whole-body momentum through sensing, contact forces, coordinated limbs and fast control before disturbances become falls.
The Robot Knows What It Carries
Payload awareness lets humanoids estimate mass, center of gravity and external forces so motion remains stable, efficient, responsive and safe.
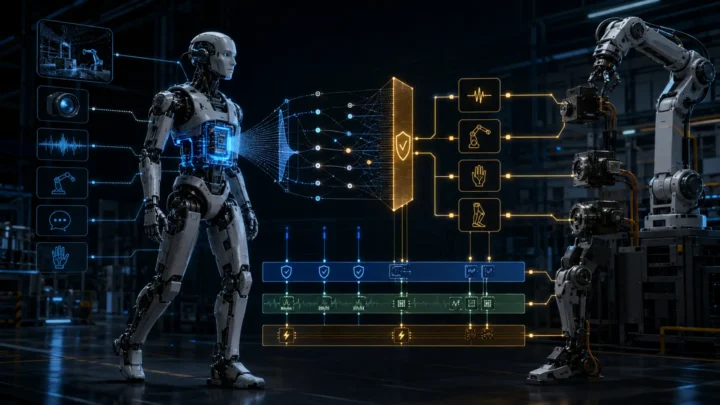
Commit Before Act
Humanoid intelligence becomes dependable when probabilistic AI proposals become bounded, time-valid, confidence-aware commitments executed and verified by deterministic physical-control architectures.
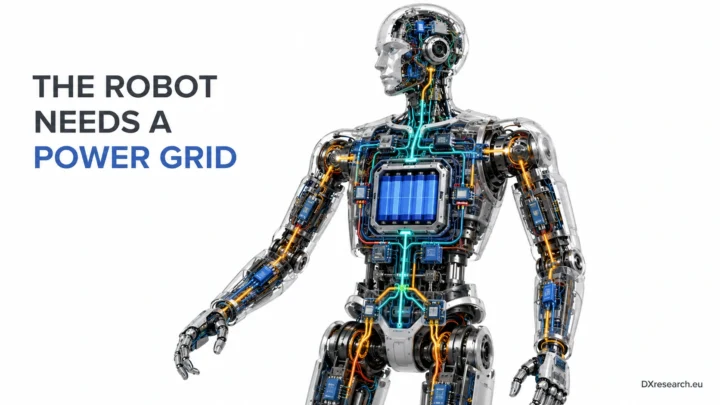
The Robot Needs a Power Grid
Humanoid power must become a distributed, protected, observable grid that routes energy safely across actuators, compute, sensing, and regenerative loads.