Latest posts
When Robots Learn to Feel
Tactile intelligence links sensing, local reflexes, communication, control and power, enabling humanoid hands to grasp objects safely, reliably and efficiently.
Situational Safety
Humanoid safety requires context-aware, independently assured responses that preserve control, reduce risk, and adapt without surrendering authority to AI models.
Strength
Force and torque awareness turns humanoid actuation into measurable physical intelligence, enabling safer contact, better dexterity, diagnostics, learning, and control.
Thermal Management Economic
Thermal efficiency, semiconductor losses, and cooling architecture determine sustained humanoid performance, reliability, maintainability, and fleet economics beyond battery capacity alone.
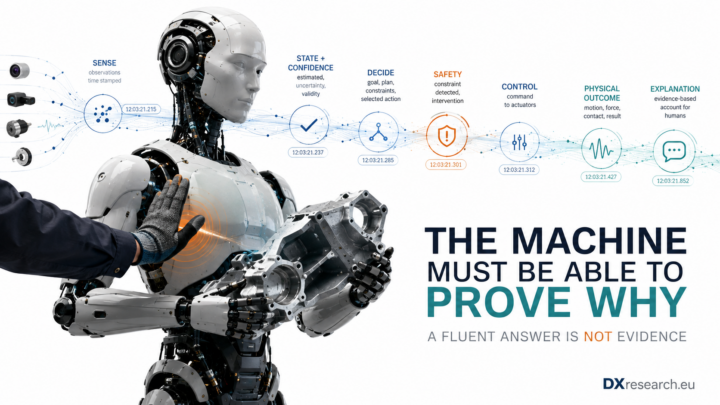
The Machine That Must Explain Itself
Trustworthy robots must explain physical actions with synchronized evidence, causal provenance, uncertainty, safety context and verifiable outcome records for humans.
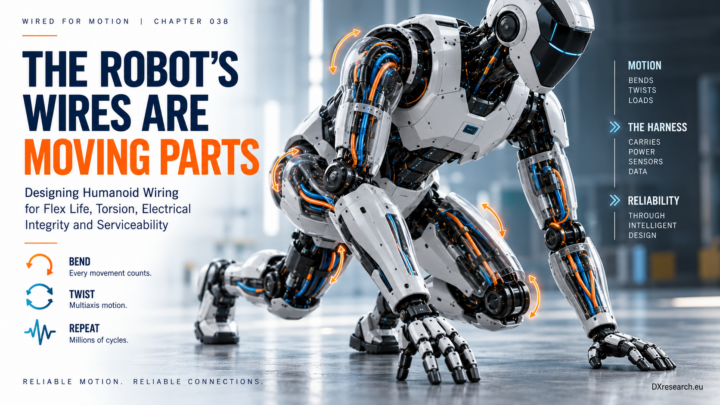
Wires Are Moving Parts
Humanoid wiring moves with every joint, making flex life, torsion, routing, connectors, electrical integrity, diagnostics, and serviceability fundamental reliability requirements.
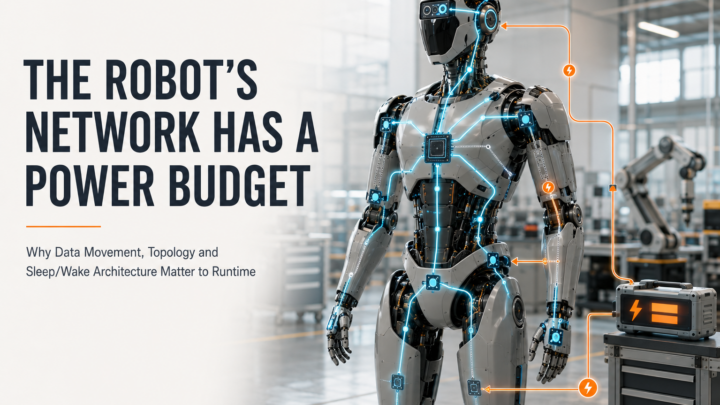
Network Power Budget
Humanoid communication consumes persistent energy; topology, bandwidth, active interfaces, and selective sleep states therefore belong inside the robot runtime budget.
Black Box: Physical AI Must Preserve the Evidence
When a robot drops an object or makes unexpected contact, ordinary logs may leave the decisive sequence unresolved. Physical AI needs protected event memory linking requests, commands and measured response. A deliberately engineered recorder can preserve evidence through failure, expose uncertainty and support accountability without turning the workplace into permanent
Black Box: Physical AI Must Preserve the Evidence
Robots need protected event evidence linking decisions, commands and physical outcomes, enabling trustworthy reconstruction after failures without permanent workplace surveillance.
The Robot Should Know When to Sleep
Humanoid efficiency is not only a motion problem. Industrial robots may spend large portions of a mission waiting, monitoring or docked. A robot-wide hierarchy of power states can cut nonproductive energy, but only if wake latency, mechanical safety and retained-state validity are engineered together.
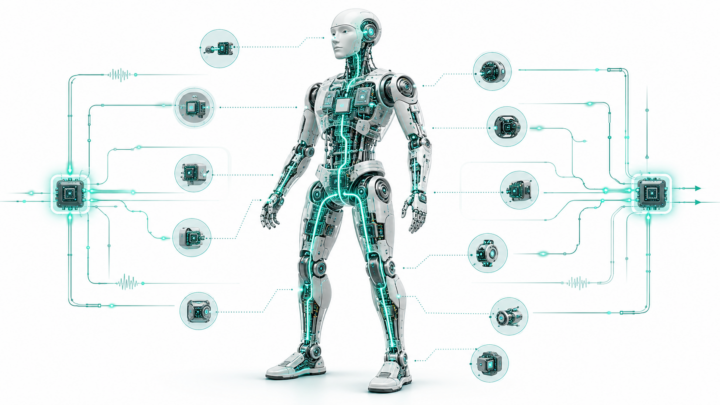
Every Bit Has a Power Cost
Internal communication in humanoids is a persistent electrical load shaped more by topology, endpoint count and power states than by raw bandwidth. A 40-DoF engineering model compares EtherCAT, CAN-FD, Ethernet, T1S and zonal designs, showing how local control, segmentation and sleep management can change mission-integrated network energy by several-fold.
Always ready?
Humanoid robots need coordinated power states that cut mission energy while preserving awareness, safe wake-up, readiness, and trustworthy retained state.