
Latest posts
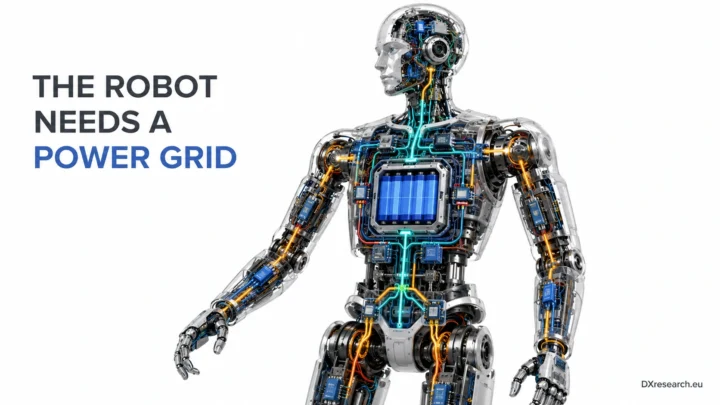
The Robot Needs a Power Grid
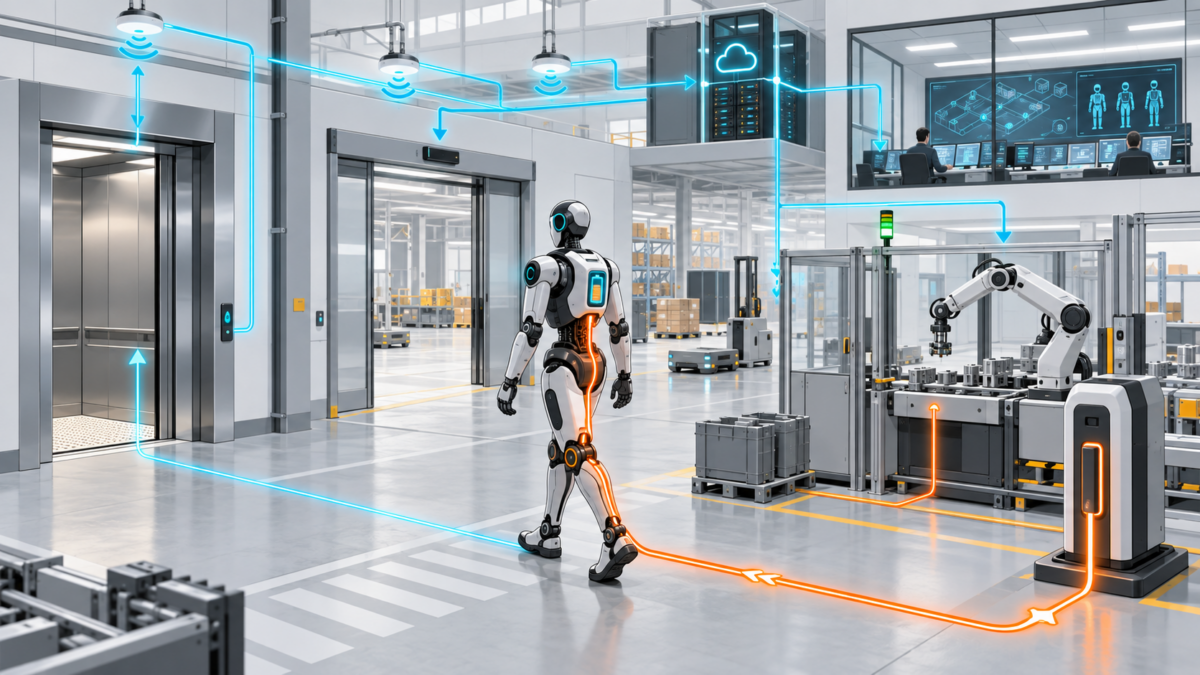
Humanoid power must become a distributed, protected, observable grid that routes energy safely across actuators, compute, sensing, and regenerative loads.
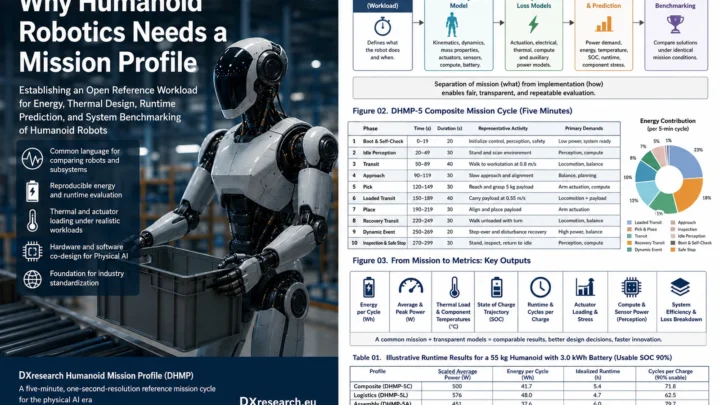
Why Humanoid Robotics Needs a Mission Profile
A common humanoid mission profile makes energy, thermal, runtime, and semiconductor comparisons reproducible across robots, tasks, laboratories, and development teams.
The Robot Must Survive the Weather
Outdoor humanoids require environmental robustness across sensing, power, sealing, diagnostics, temperature, moisture, dust, connectors, and semiconductor operating margins throughout deployment.
Power Integrity Is Robot Intelligence
Humanoid performance depends on power integrity: stable distributed energy delivery that preserves motion, perception, computation, safety, and availability under transients.
The Robot Must Be Electromagnetically Quiet
Humanoid reliability depends on controlling electromagnetic noise across power electronics, sensors, communication links, grounding, shielding, filtering, and semiconductor interfaces reliably.
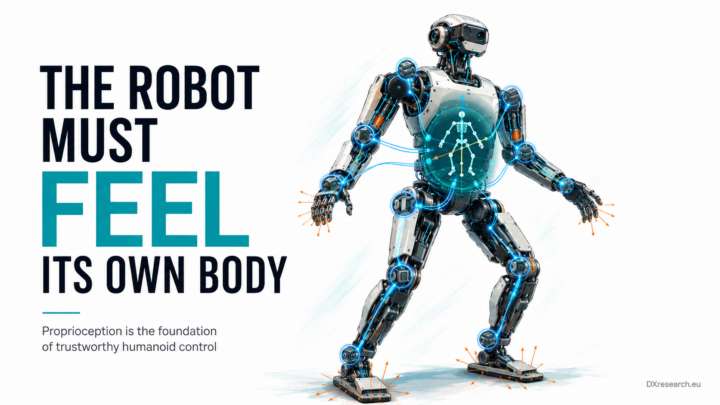
Feel – Your Own Body
Proprioception turns joint, inertial, contact and load measurements into trustworthy body-state estimates for safer, more capable, serviceable humanoid motion systems.
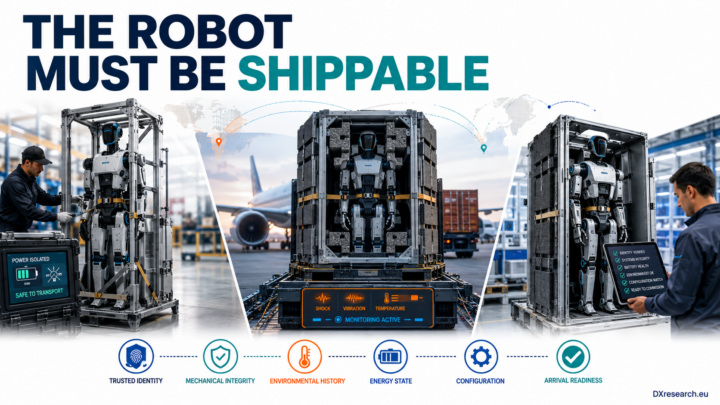
Design for Shipping
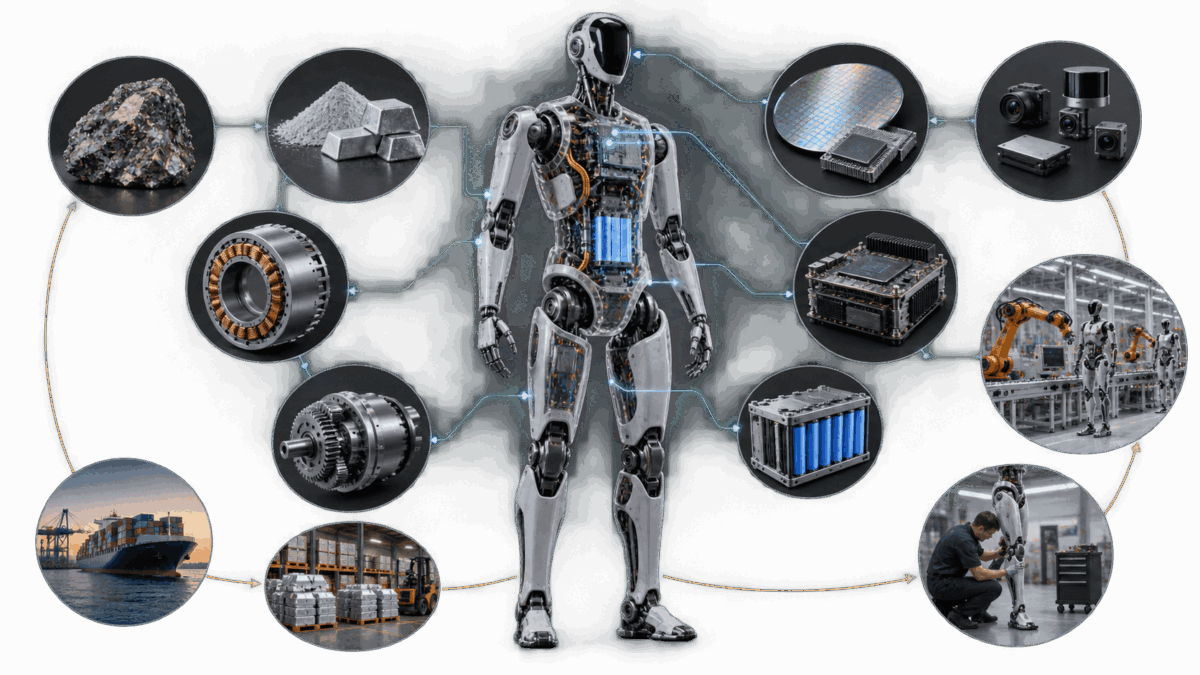
Humanoid robots scale only when transport, storage, battery isolation, shock resilience, commissioning, and traceability are engineered into architecture from inception.
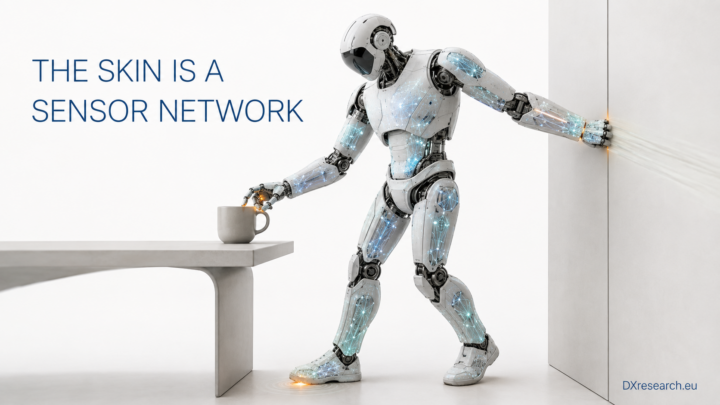
The Skin Is a Sensor Network
Whole-body tactile networks turn robot surfaces into distributed intelligence, linking contact sensing, edge processing, safety, control, diagnostics, and continuous learning.
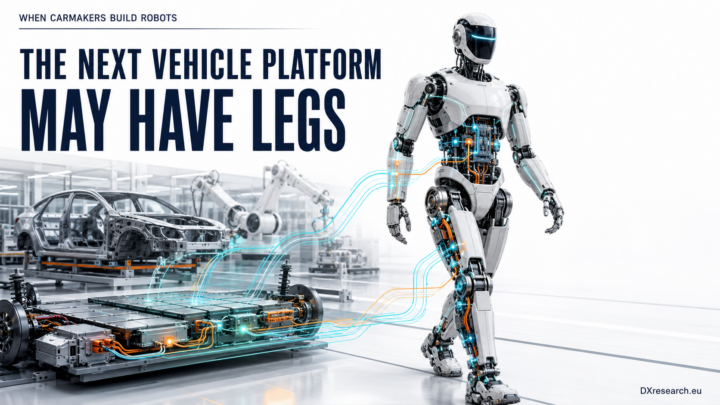
When Carmakers Build Robots
Automotive OEMs become robot makers transferring electric drive sensing safety AI manufacturing and supplier architectures into emerging Physical AI ecosystems.
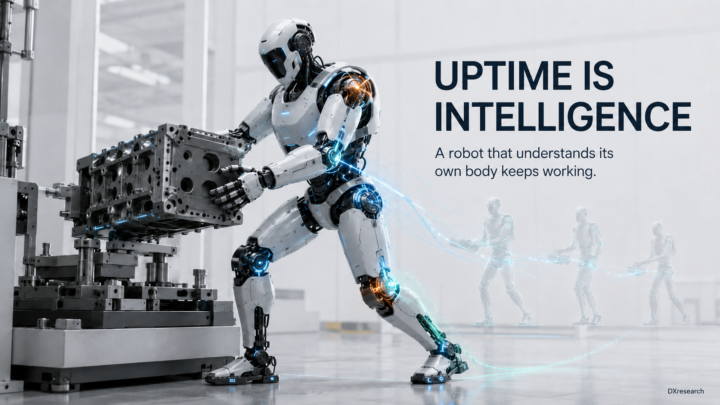
Uptime Is Intelligence
Humanoid scale depends on architectures that detect degradation, preserve safe capability, accelerate repair, and convert fleet evidence into continuous improvement.
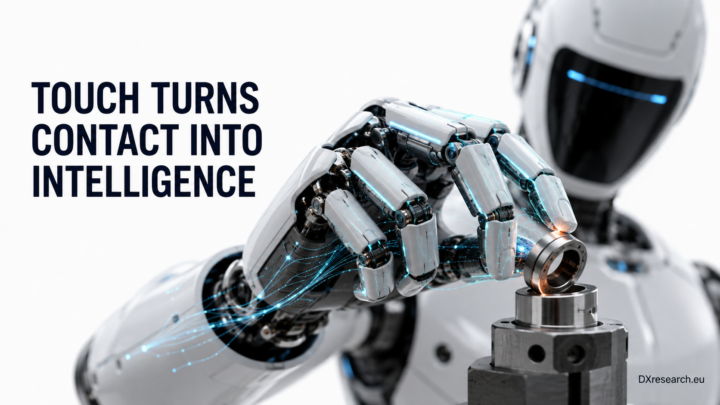
When Robots Learn to Feel
Tactile intelligence links sensing, local reflexes, communication, control and power, enabling humanoid hands to grasp objects safely, reliably and efficiently.
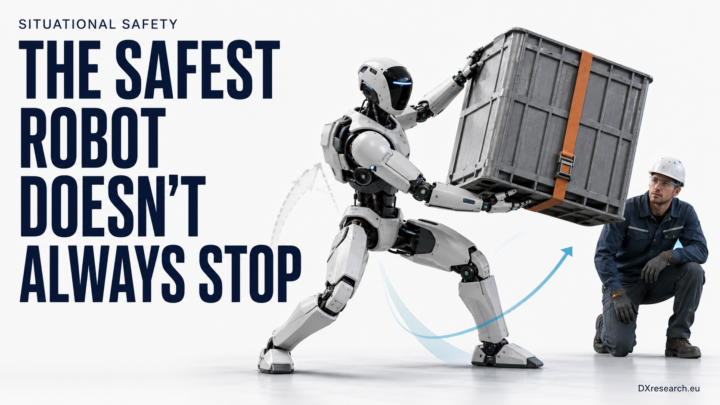
Situational Safety
Humanoid safety requires context-aware, independently assured responses that preserve control, reduce risk, and adapt without surrendering authority to AI models.

