Latest posts
Always Ready?
Humanoid robots need coordinated power states that reduce mission energy without compromising awareness, stability or safe recovery. A five-state architecture aligns motion, perception, compute, communication and safety with explicit readiness contracts, wake sources and retained-state rules. The decisive metric is not sleep current, but energy consumed per productive mission hour.
The Robot Must Know When Electricity Escapes
A humanoid can appear electrically healthy while insulation quietly deteriorates. As batteries, inverters, motors, chargers and moving harnesses share a touchable conductive body, insulation becomes a runtime system property. Continuous monitoring, contextual diagnostics and controlled responses can turn an invisible electrical weakness into actionable health information before it becomes a
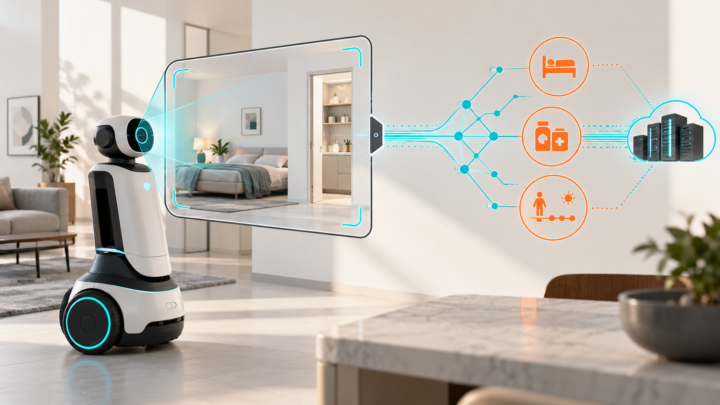
A Robot Can Reveal the Room Without Sharing the Image
Keeping camera streams onboard does not make a robot private. Maps, object geometry and task references can still expose the spaces they describe. A defensible architecture must test every exported representation for utility and residual inference, while treating privacy, cybersecurity and functional safety as separate engineering responsibilities.
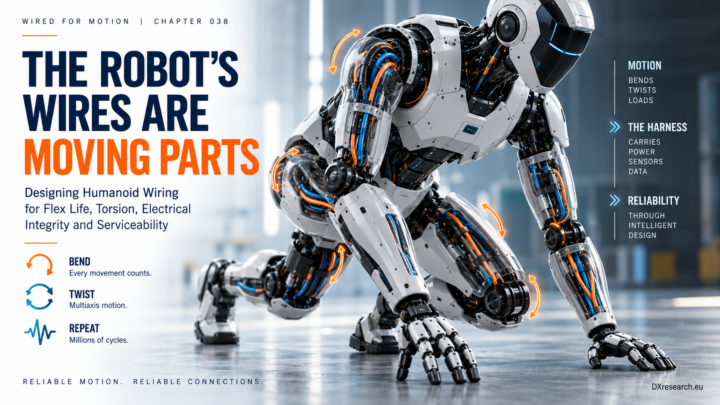
Wires Are Moving Parts
Humanoid wiring moves with every joint, making flex life, torsion, routing, connectors, electrical integrity, diagnostics, and serviceability fundamental reliability requirements.
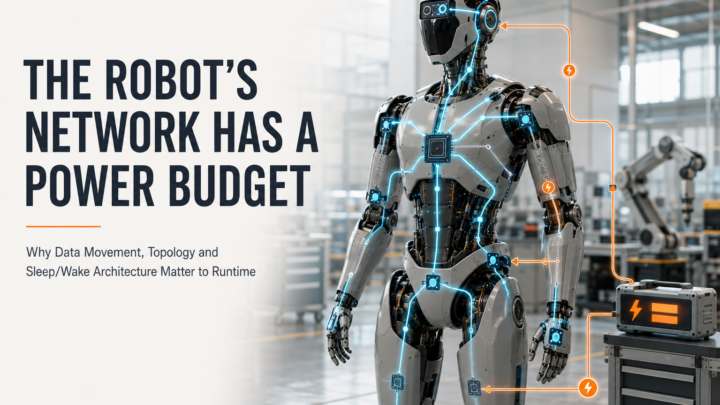
Network Power Budget
Humanoid communication consumes persistent energy; topology, bandwidth, active interfaces, and selective sleep states therefore belong inside the robot runtime budget.
Black Box: Physical AI Must Preserve the Evidence
Robots need protected event evidence linking decisions, commands and physical outcomes, enabling trustworthy reconstruction after failures without permanent workplace surveillance.
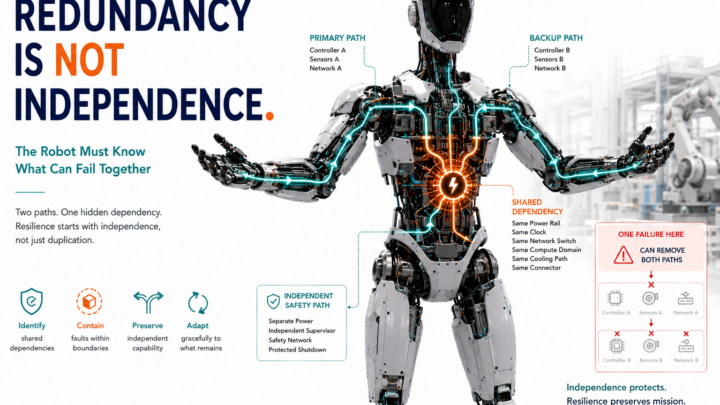
The Robot Must Know What Can Fail Together
Humanoid redundancy matters only when backup functions survive shared failures across power, timing, communication, compute, sensing, cooling, and supervision domains.
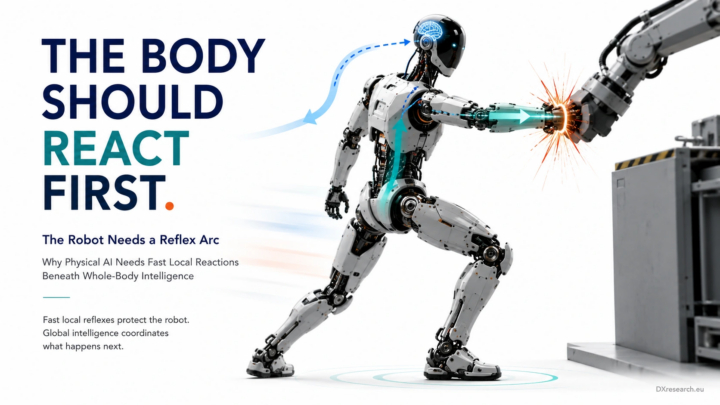
The Reflex Arc
Fast local reflex loops let humanoids mitigate physical disturbances immediately while whole-body intelligence coordinates recovery, safety, balance and task continuity.
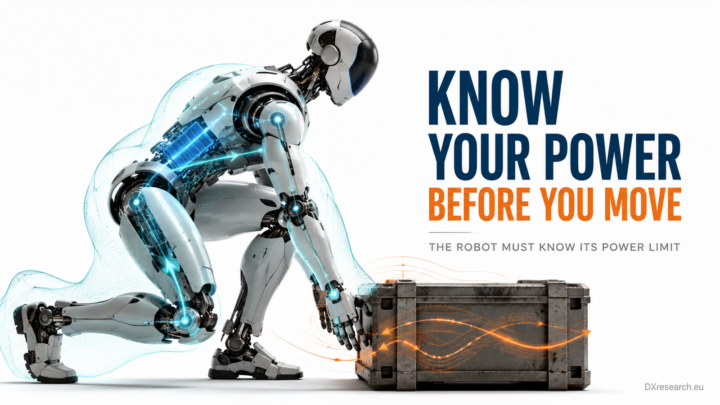
Know Your Power
A robot needs a real-time battery power envelope before motion, because remaining energy alone cannot guarantee the next maneuver safely.
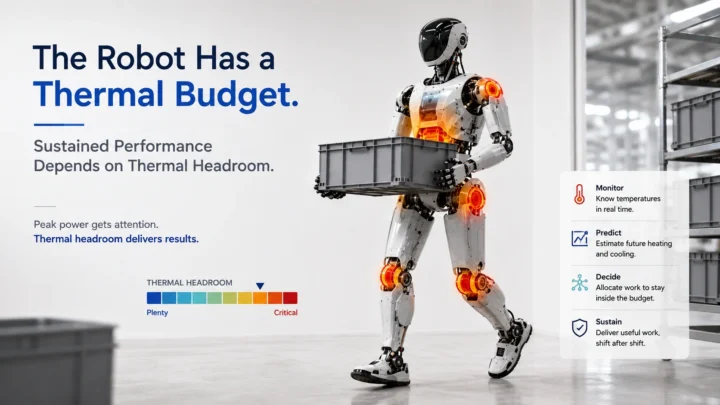
The Robot Has a Thermal Budget
Thermal headroom determines whether humanoid peak performance can become sustained useful work across actuators, compute, batteries and power electronics reliably.
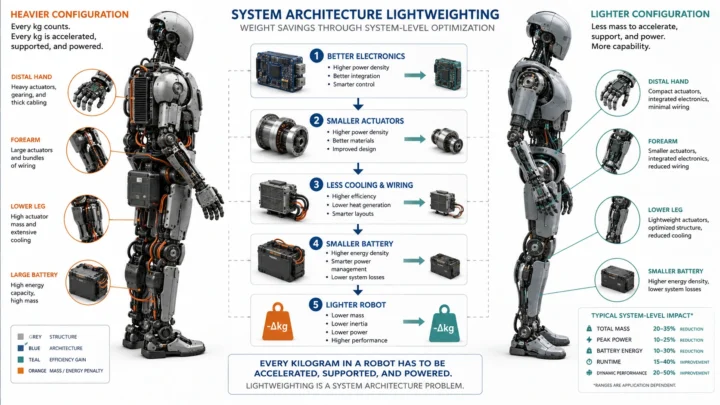
Every Kilogram Has to Move
Robot mass cascades through torque, energy, materials, cooling, wiring and batteries, making lightweighting a system architecture problem for scalable robotics.
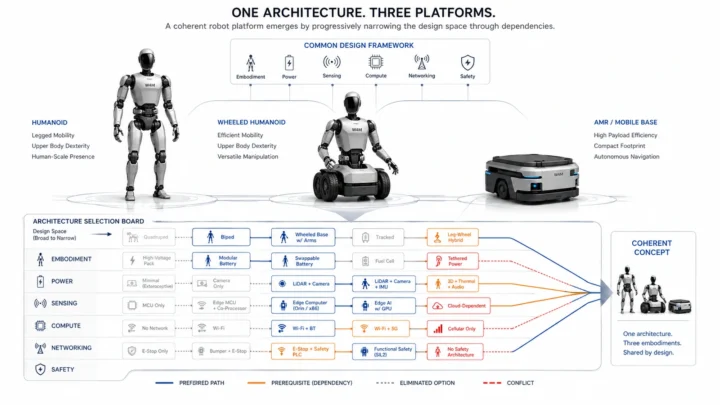
Morphological
Dependency-aware morphological design progressively narrows robot architectures, exposing prerequisites and conflicts before detailed sizing locks expensive subsystem decisions into hardware.