The Robot Needs an Immune System
Robots need distributed trust mechanisms that detect abnormalities, contain faults, preserve safe capability, recover securely, and learn across operational fleets.
Robots need distributed trust mechanisms that detect abnormalities, contain faults, preserve safe capability, recover securely, and learn across operational fleets.
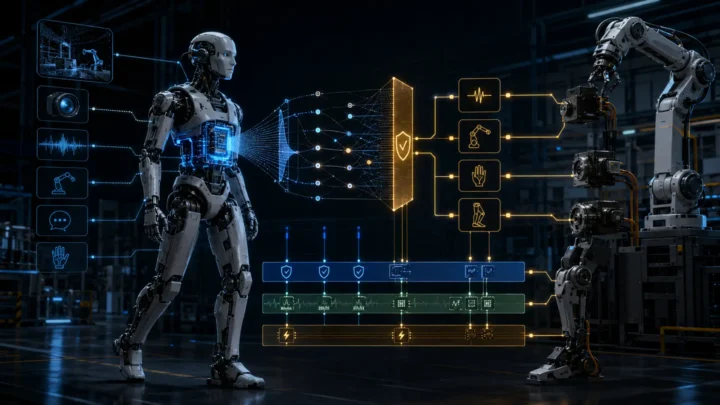
Humanoid intelligence becomes dependable when probabilistic AI proposals become bounded, time-valid, confidence-aware commitments executed and verified by deterministic physical-control architectures.
Memory bandwidth, locality and data movement will constrain whole-body robot intelligence before nominal accelerator throughput reaches its advertised computational limits.
Hardware-rooted identity, attestation and lifecycle evidence will determine whether humanoid robots earn trust, authorization, serviceability and market access at scale.
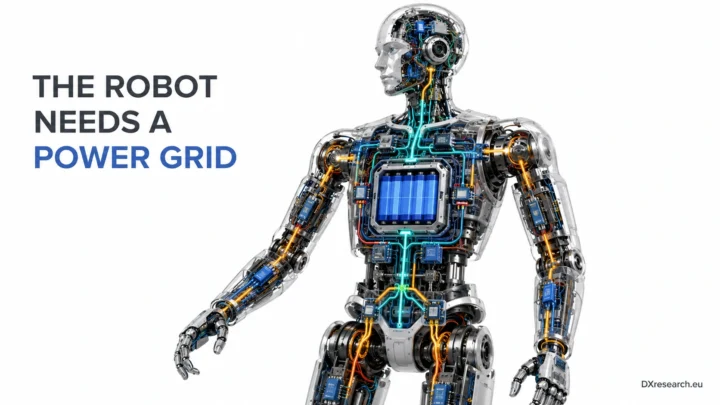
Humanoid power must become a distributed, protected, observable grid that routes energy safely across actuators, compute, sensing, and regenerative loads.
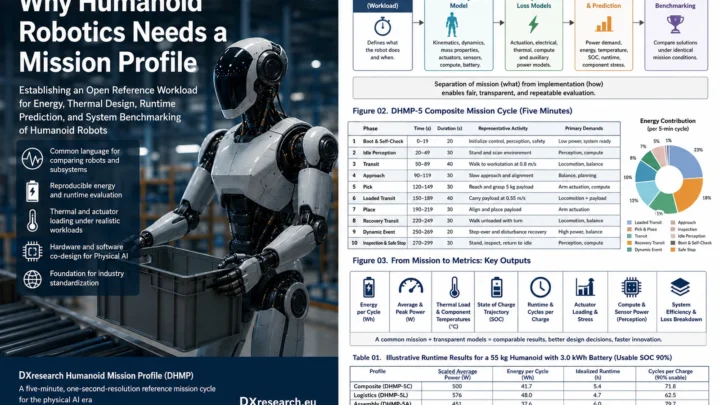
A common humanoid mission profile makes energy, thermal, runtime, and semiconductor comparisons reproducible across robots, tasks, laboratories, and development teams.
Outdoor humanoids require environmental robustness across sensing, power, sealing, diagnostics, temperature, moisture, dust, connectors, and semiconductor operating margins throughout deployment.
Humanoid performance depends on power integrity: stable distributed energy delivery that preserves motion, perception, computation, safety, and availability under transients.
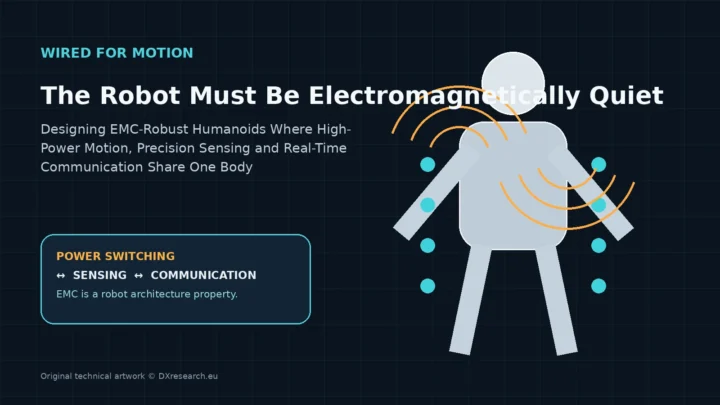
Humanoid reliability depends on controlling electromagnetic noise across power electronics, sensors, communication links, grounding, shielding, filtering, and semiconductor interfaces reliably.
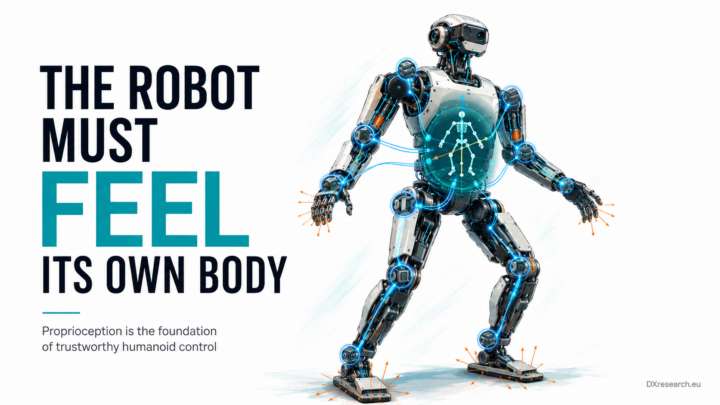
Proprioception turns joint, inertial, contact and load measurements into trustworthy body-state estimates for safer, more capable, serviceable humanoid motion systems.