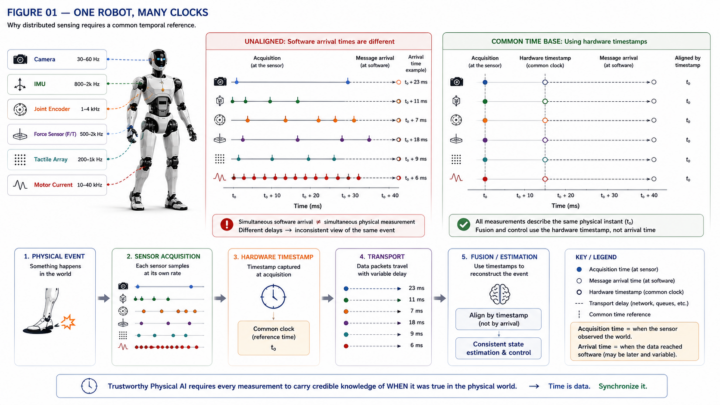
The Robot Needs a Common Clock
Humanoid control needs synchronized timestamps so distributed sensors, actuators, estimators and safety logic describe the same physical moment reliably together.

Humanoid control needs synchronized timestamps so distributed sensors, actuators, estimators and safety logic describe the same physical moment reliably together.
Human-facing Physical AI needs sensing architectures validated across physiological diversity, with adaptive calibration, context awareness, signal quality and explicit confidence.
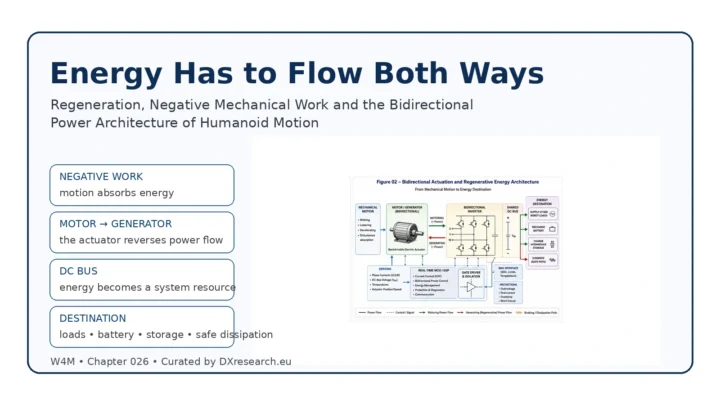
Humanoid efficiency depends on capturing, routing and absorbing negative mechanical work through coordinated bidirectional actuation, power electronics and energy control.
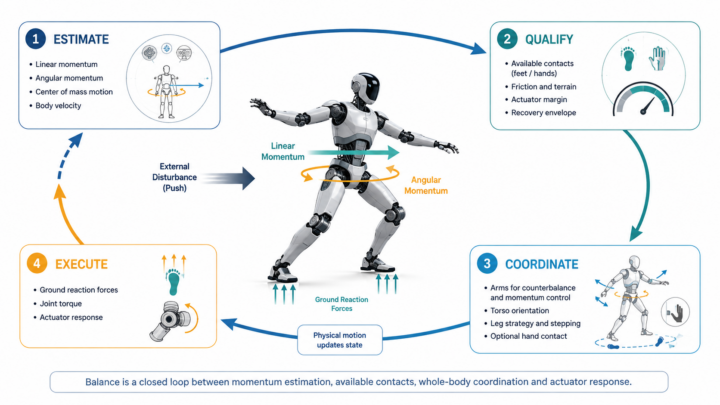
Humanoid balance depends on managing whole-body momentum through sensing, contact forces, coordinated limbs and fast control before disturbances become falls.
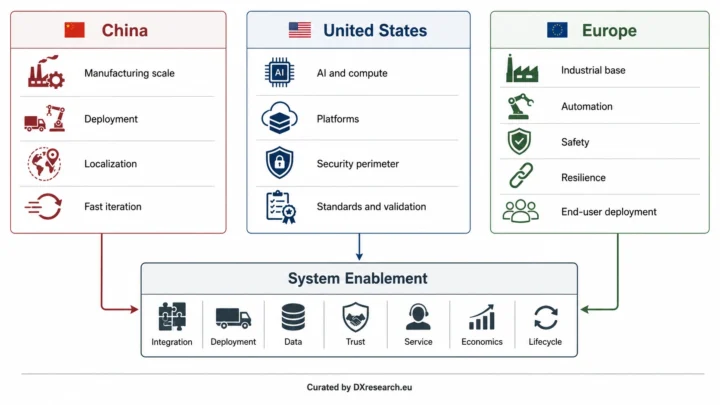
China, the United States and Europe are building distinct Physical AI markets, making system enablement the emerging route to scale.
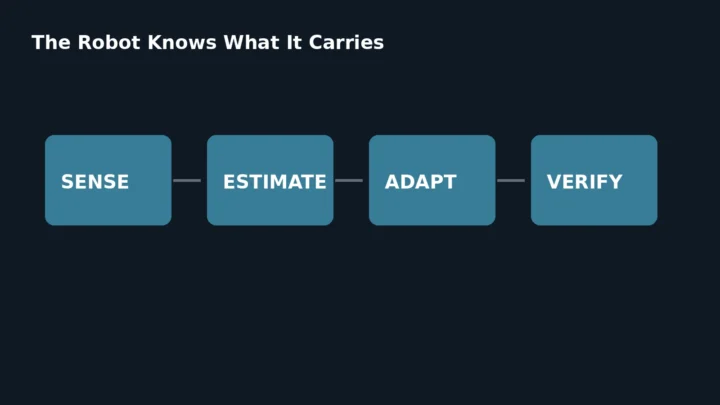
Payload awareness lets humanoids estimate mass, center of gravity and external forces so motion remains stable, efficient, responsive and safe.
Robots need distributed trust mechanisms that detect abnormalities, contain faults, preserve safe capability, recover securely, and learn across operational fleets.
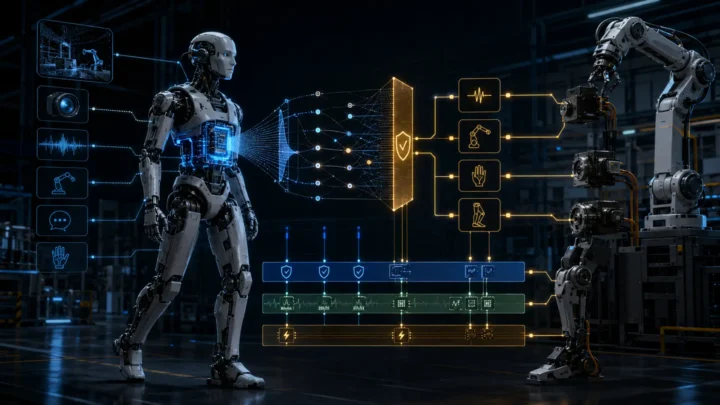
Humanoid intelligence becomes dependable when probabilistic AI proposals become bounded, time-valid, confidence-aware commitments executed and verified by deterministic physical-control architectures.
Memory bandwidth, locality and data movement will constrain whole-body robot intelligence before nominal accelerator throughput reaches its advertised computational limits.
Hardware-rooted identity, attestation and lifecycle evidence will determine whether humanoid robots earn trust, authorization, serviceability and market access at scale.

