
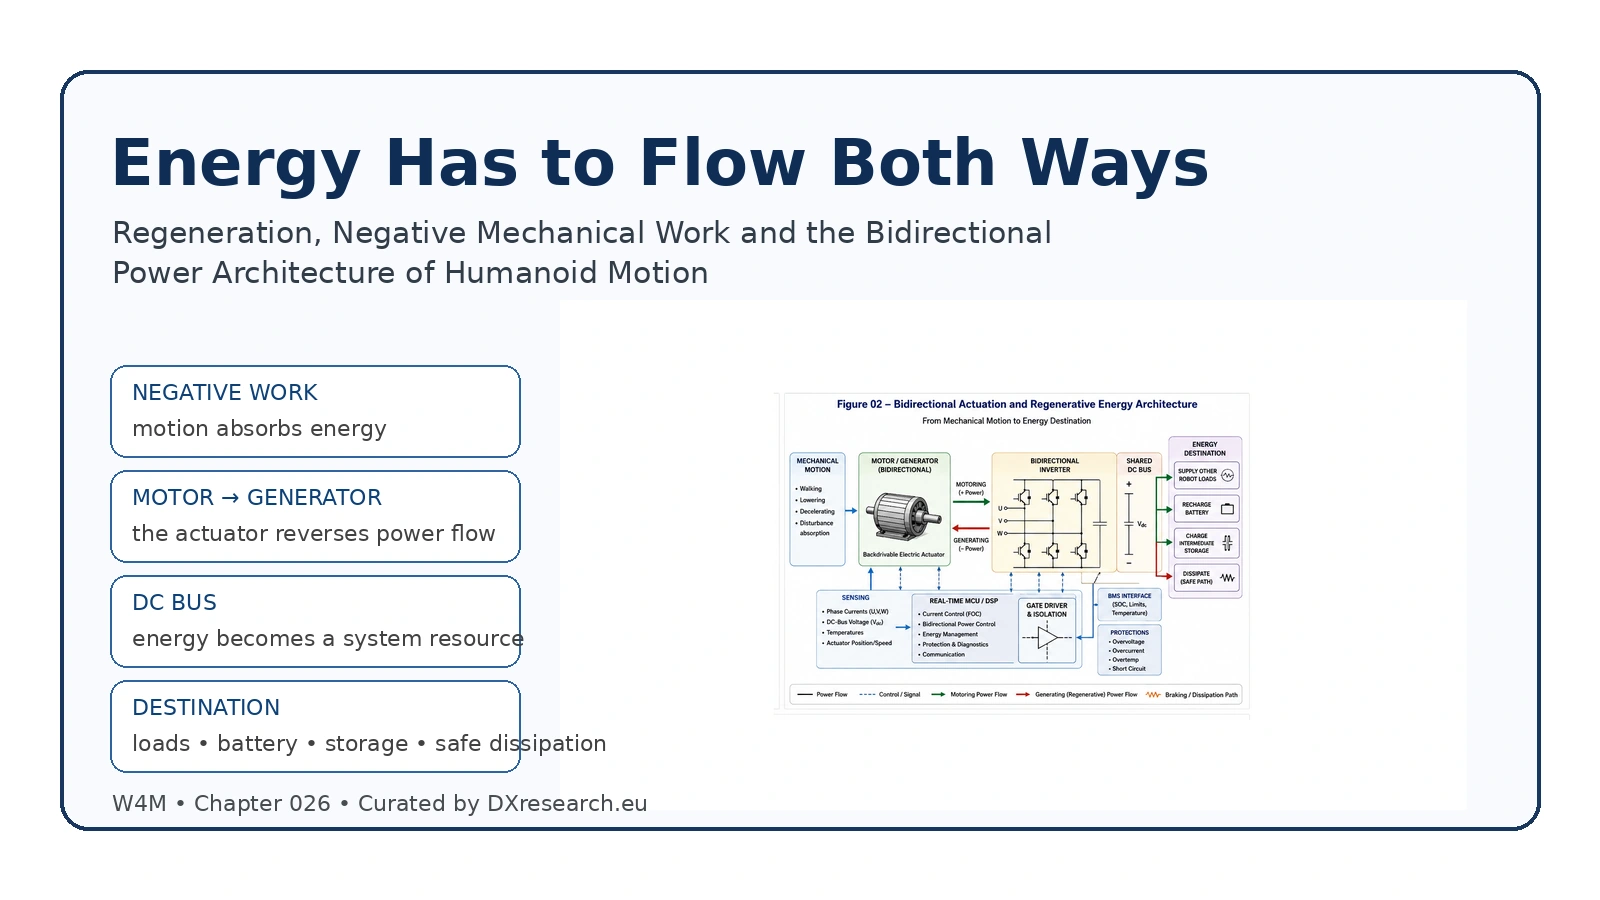
Regeneration, Negative Mechanical Work and the Bidirectional Power Architecture of Humanoid Motion
Humanoid efficiency depends on capturing, routing and absorbing negative mechanical work through coordinated bidirectional actuation, power electronics and energy control.

