
Technical Article
The Robot Needs a Common Clock
Time Synchronization, Hardware Timestamping and Temporal Integrity Across the Humanoid Body
Humanoid control needs synchronized timestamps so distributed sensors, actuators, estimators and safety logic describe the same physical moment reliably together.
Time Is Part of Every Measurement
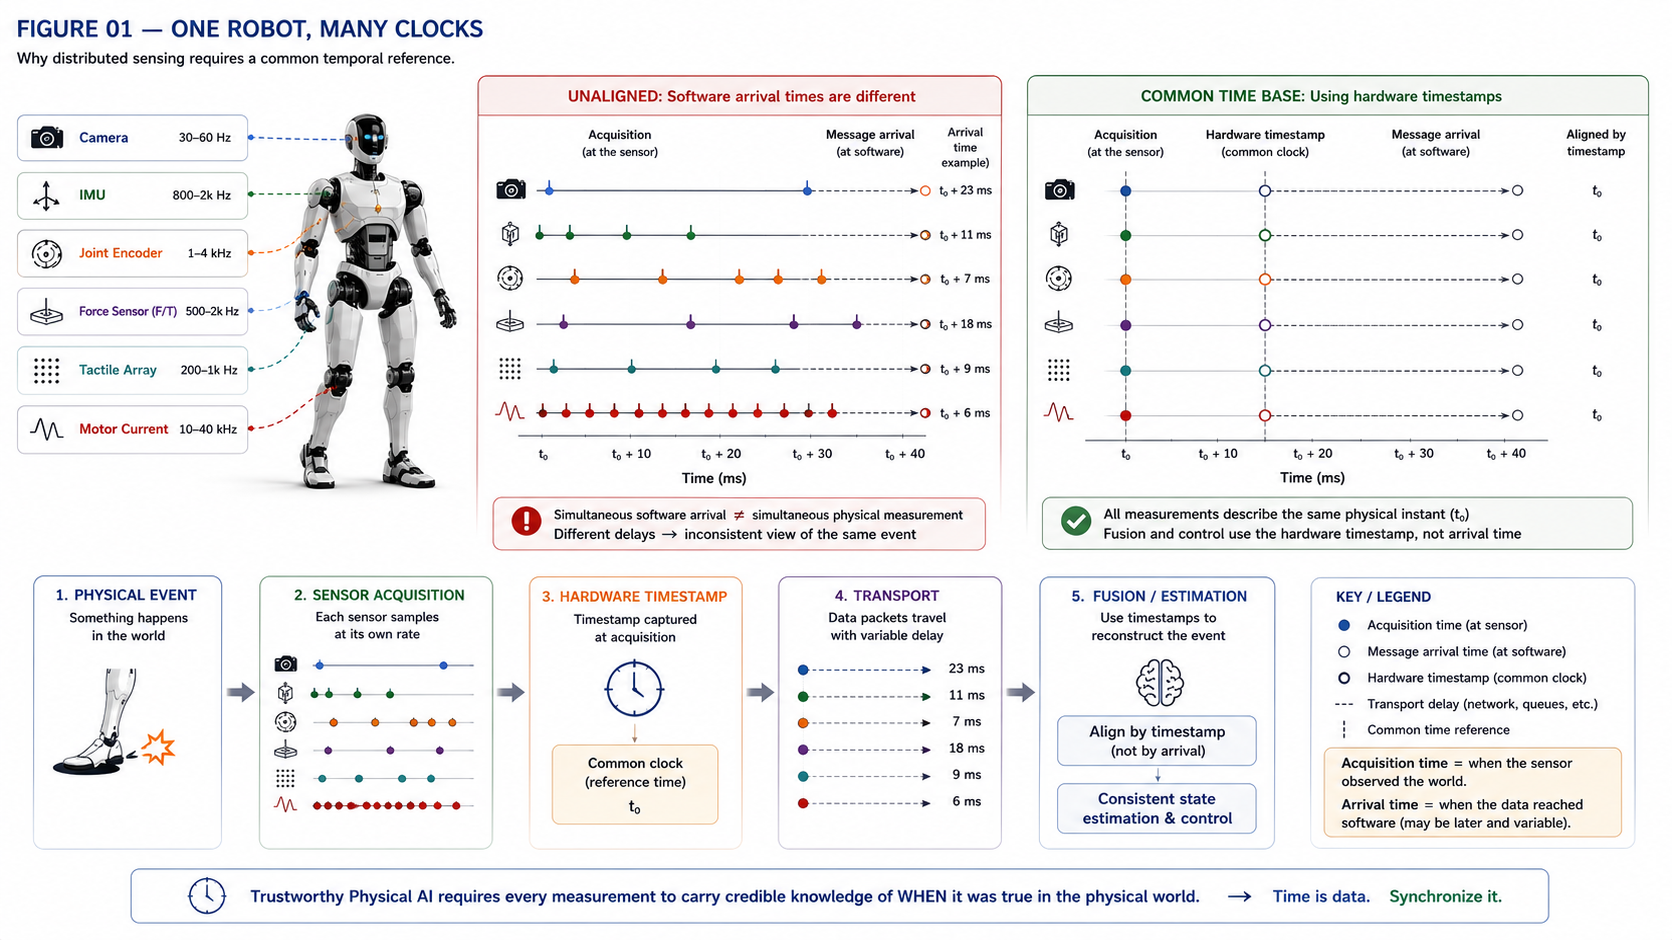
Temporal integrity Acquisition timestamp Clock offset Clock drift Jitter PTP Distributed clock Propagation-delay compensation Stale data. A sensor value without credible timing can be numerically accurate yet physically misleading. The key distinction is between acquisition time and later software arrival.
One Robot, Many Clocks
Cameras, IMUs, encoders and motor-control nodes run at different rates and may own independent oscillators. IEEE 1588 defines precision clock synchronization for distributed measurement and control systems. [1] Its amendment continues that standards framework. [2]
Hardware Timestamping Moves Time Closer to Physics
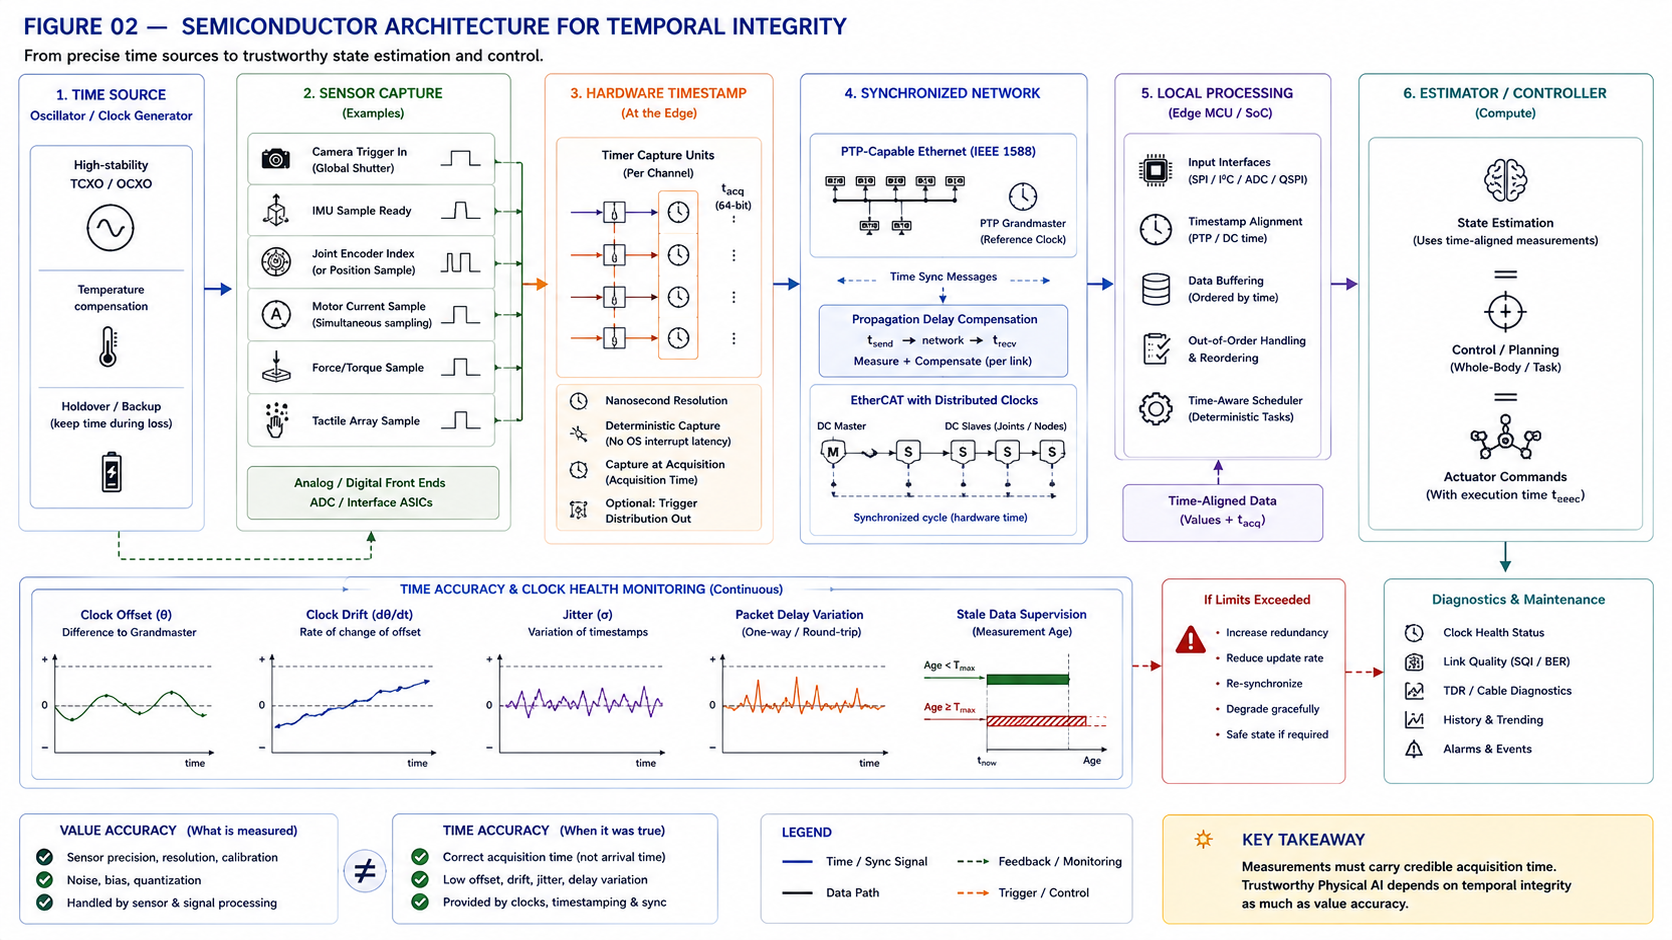
Timestamping near sensor acquisition reduces uncertainty introduced by interrupts, queues and operating-system scheduling. NVIDIA robotics platforms document synchronized sensor acquisition and correlated timestamp mechanisms. [4] [5]
Networks Must Carry Time as Well as Data
EtherCAT Distributed Clocks provide synchronized local hardware clocks and compensate communication propagation delay. [3] PTP hardware-clock infrastructure similarly exposes hardware timing capabilities to software. [8]
Controllers Need Data Age, Not Only Data Values
State estimation should reason about measurement age, clock error and transport uncertainty. Old evidence can be classified as stale rather than silently fused into a current state. This matters when fast body motion turns milliseconds of timing error into position, velocity or force inconsistency.
Simulation Needs the Same Temporal Contract
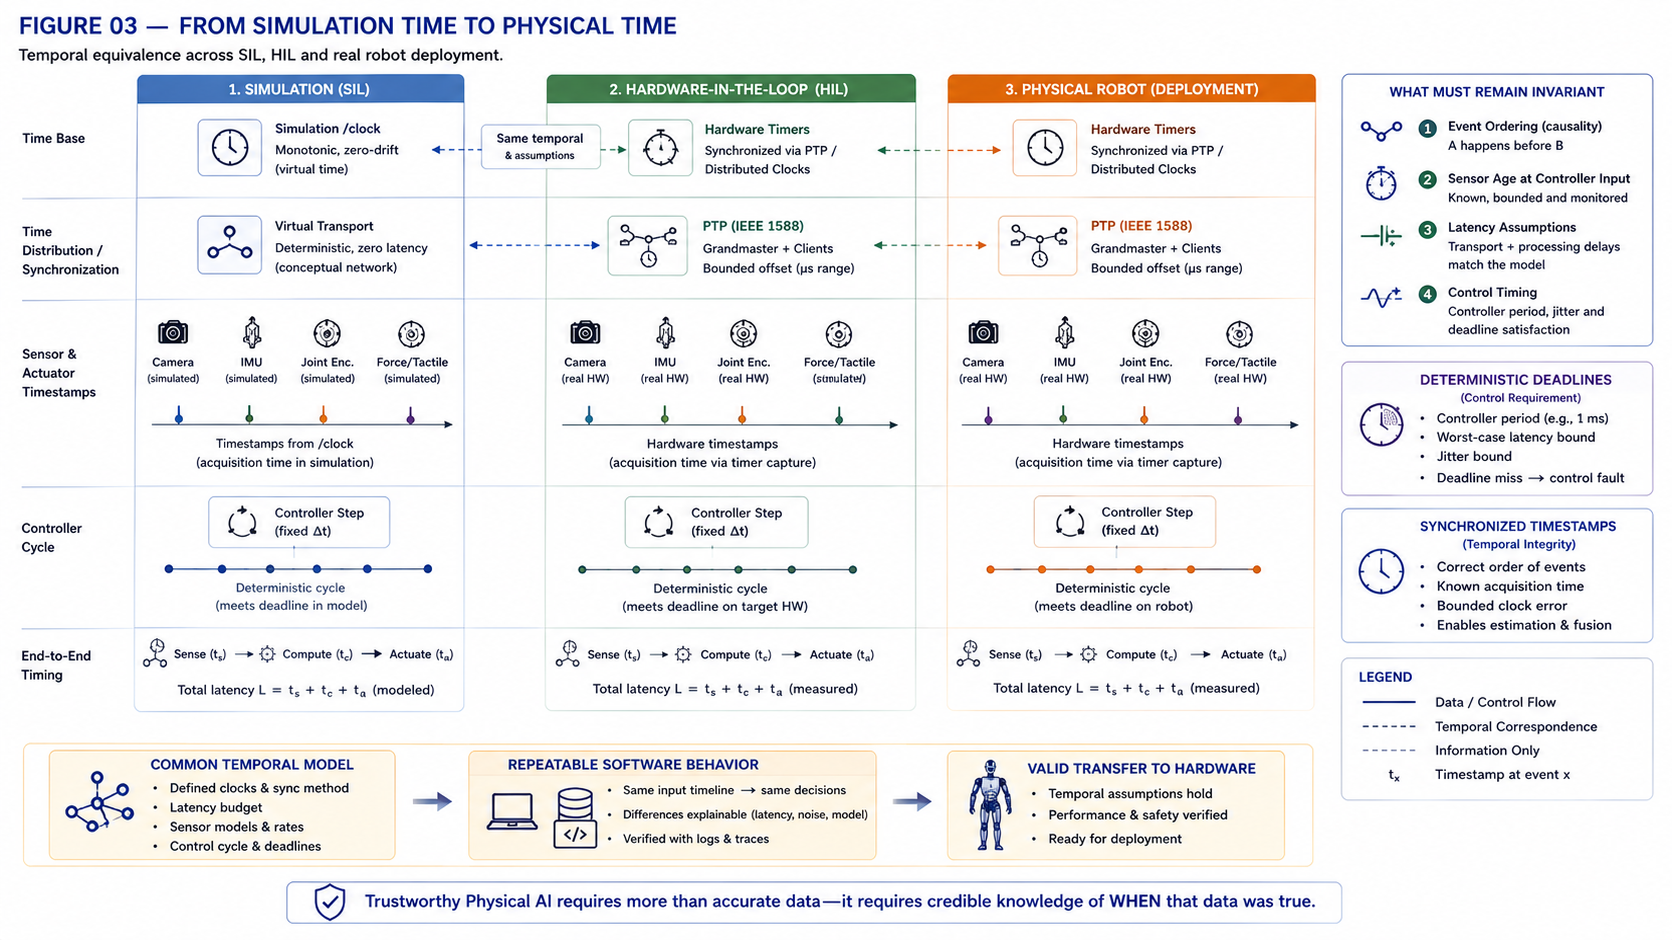
ROS 2 explicitly abstracts time for robotic systems. [6] Isaac Sim can publish simulation time so distributed ROS nodes operate against a shared virtual clock. [7] That temporal contract helps software preserve event ordering and sensor-age assumptions across simulation and hardware.
Conclusion
A scalable humanoid needs temporal integrity across its body. Every critical measurement should answer two questions: what was observed, and when was it physically true? Synchronization, timestamps and clock-health diagnostics make distributed evidence coherent enough for perception, control and safety.
References
- IEEE. IEEE 1588-2019 Standard for a Precision Clock Synchronization Protocol for Networked Measurement and Control Systems. 2019. https://standards.ieee.org/standard/1588-2019.html
- IEEE. IEEE 1588a-2023 Amendment. 2023. https://standards.ieee.org/
- EtherCAT Technology Group. Distributed Clocks for High-Precision Synchronization. tbd. https://www.ethercat.org/
- NVIDIA. Nova Orin Developer Kit Documentation. tbd. https://nvidia-isaac-ros.github.io/
- ROS 2 Design. Clock and Time. tbd. https://design.ros2.org/articles/clock_and_time.html
- NVIDIA Isaac Sim. ROS 2 Reference Architecture / Simulation Time. tbd. https://docs.isaacsim.omniverse.nvidia.com/
- Linux Kernel Documentation. PTP Hardware Clock Infrastructure. tbd. https://docs.kernel.org/driver-api/ptp.html
Glossary
- Acquisition timestamp
- Time at which a physical quantity was sampled rather than received by software.
- Clock drift
- Change in clock offset over time.
- Clock offset
- Instantaneous difference between two clocks.
- Distributed clock
- Synchronized local hardware clock maintained across networked nodes.
- Jitter
- Variation in timing around an intended event.
- Propagation-delay compensation
- Correction for time consumed transporting synchronization information.
- PTP
- IEEE 1588 Precision Time Protocol for synchronizing clocks in distributed systems.
- Stale data
- Information whose age exceeds its valid control or estimation window.
- Temporal integrity
- Confidence that measurements and actions are correctly associated with physical time.
Sources
- Clock and Time · tbd · ROS 2 Design
https://design.ros2.org/articles/clock_and_time.html - Distributed Clocks for High-Precision Synchronization · tbd · EtherCAT Technology Group
https://www.ethercat.org/ - IEEE 1588-2019 Standard for a Precision Clock Synchronization Protocol for Networked Measurement and Control Systems · 2019 · IEEE
https://standards.ieee.org/standard/1588-2019.html - IEEE 1588a-2023 Amendment · 2023 · IEEE
https://standards.ieee.org/ - Isaac ROS Correlated Timestamp Driver · tbd · NVIDIA
https://nvidia-isaac-ros.github.io/ - Nova Orin Developer Kit Documentation · tbd · NVIDIA
https://nvidia-isaac-ros.github.io/ - PTP Hardware Clock Infrastructure · tbd · Linux Kernel Documentation
https://docs.kernel.org/driver-api/ptp.html - ROS 2 Reference Architecture / Simulation Time · tbd · NVIDIA Isaac Sim
https://docs.isaacsim.omniverse.nvidia.com/

