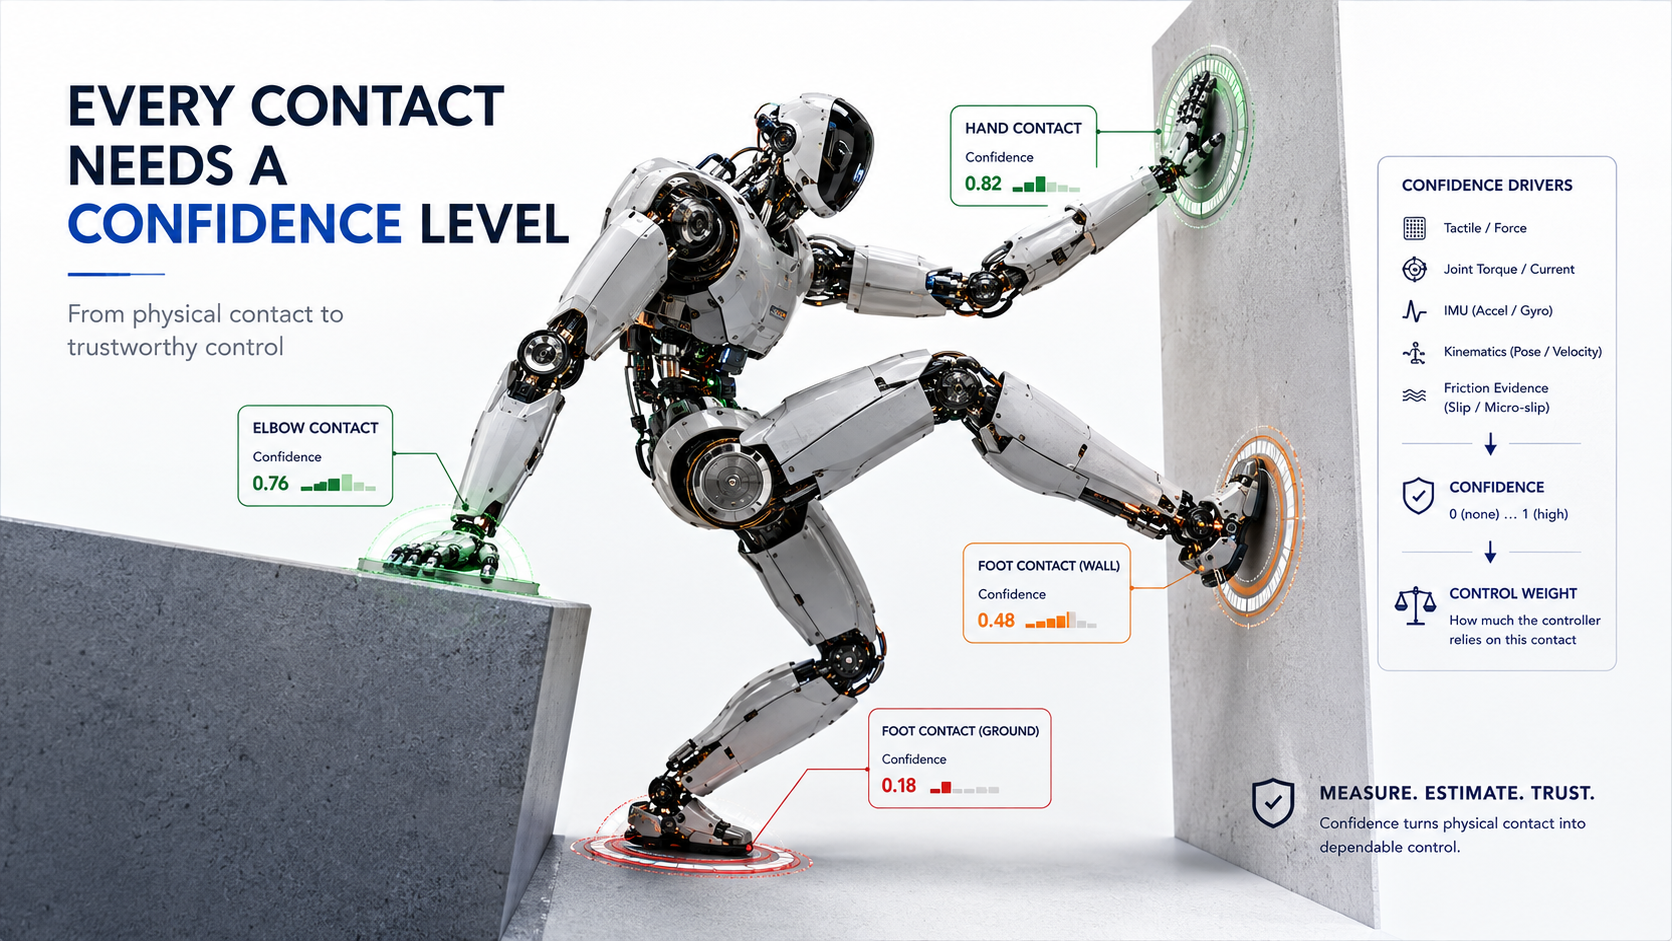
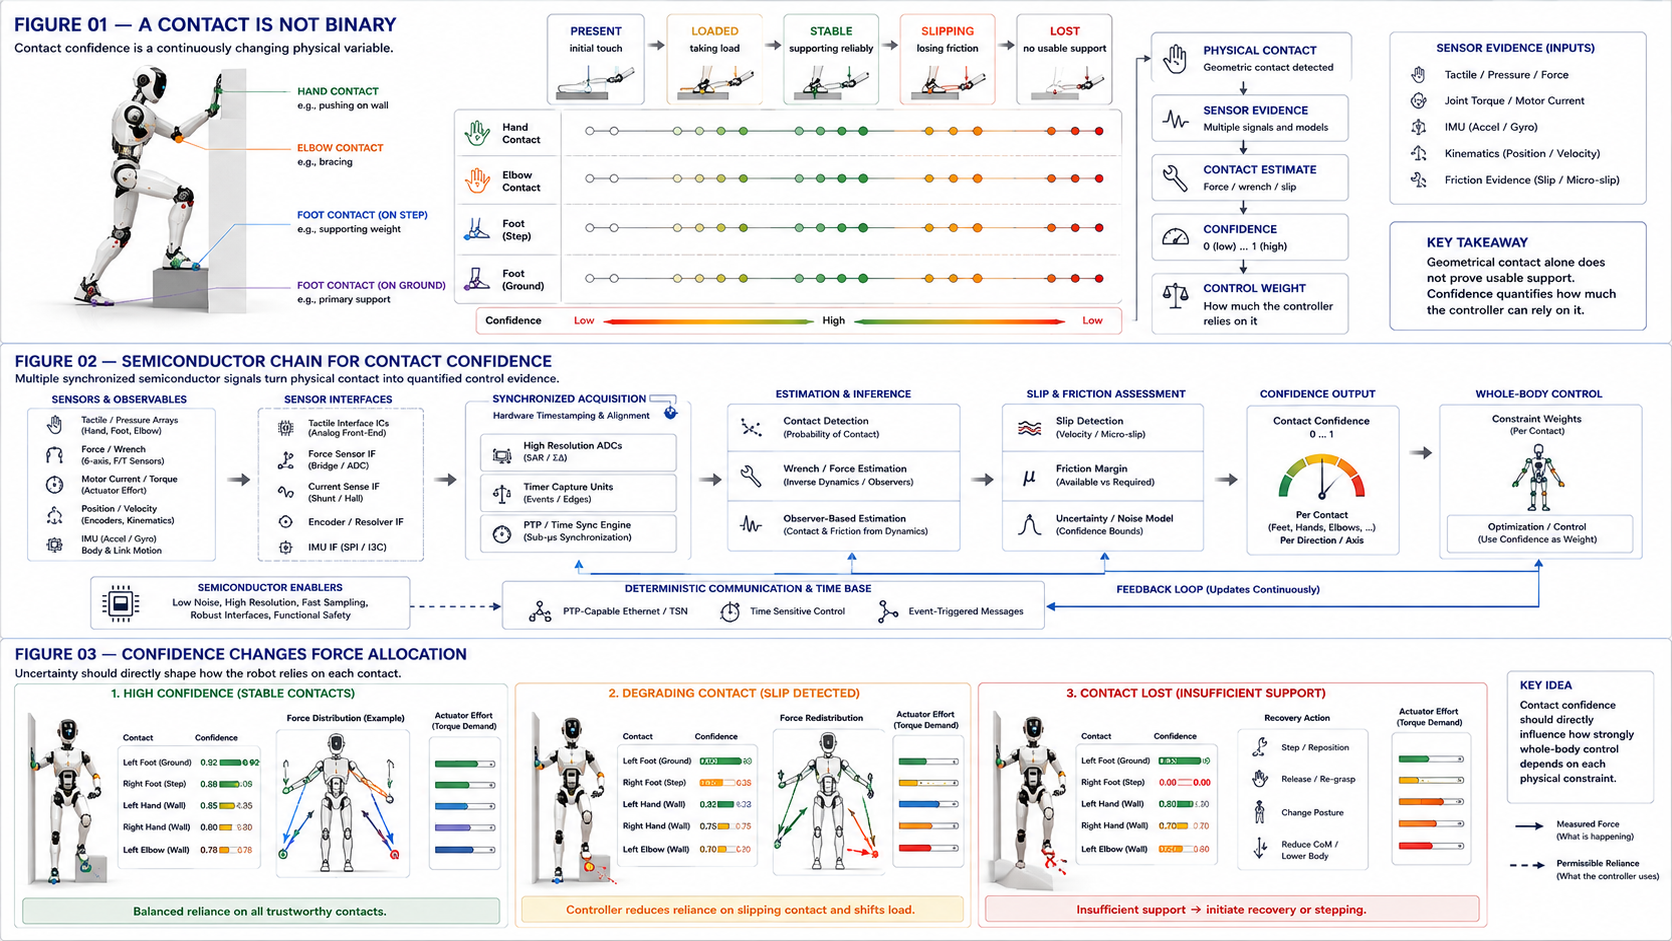
A Contact Is Not Binary
A planned support can be geometrically present while mechanically unreliable. Contact state should distinguish touching, loaded, stable, slipping and lost conditions. Humanoid research shows that external interaction can be estimated even on body parts without dedicated force sensors and used by multicontact control. [1]
Confidence Is the Missing Control Variable
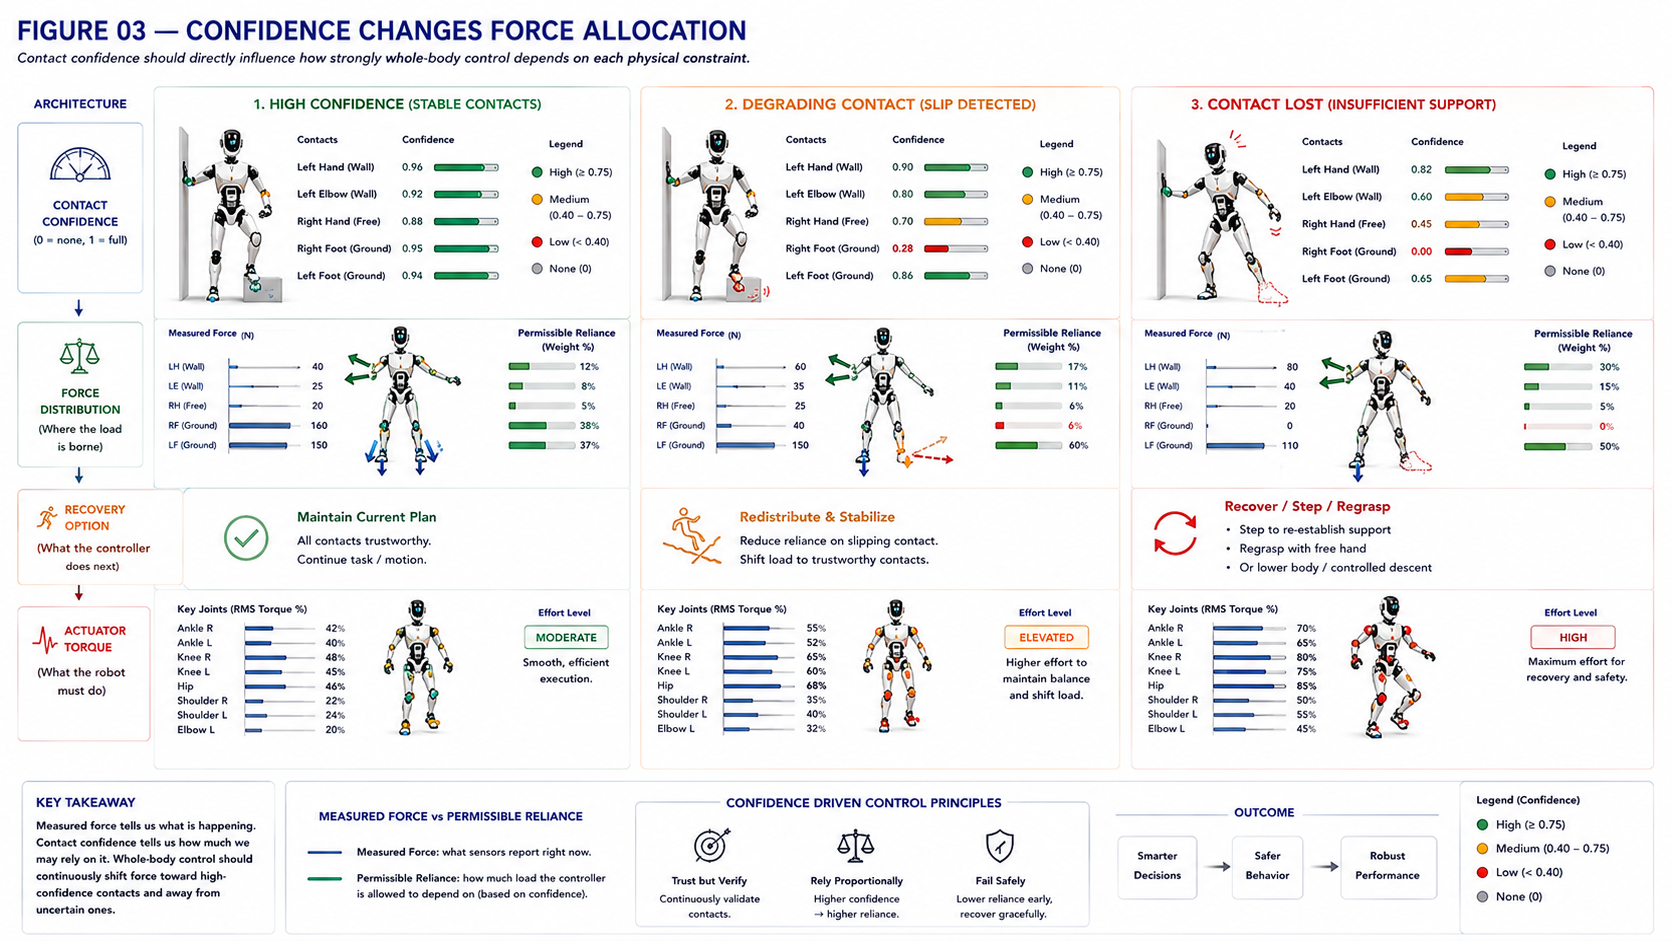
The useful question is not merely whether contact exists, but how strongly control should rely on it. Contact confidence turns heterogeneous evidence into a bounded statement about support reliability. High confidence permits stronger force allocation. Falling confidence should progressively reduce reliance before the contact disappears.
Force and Friction Must Be Estimated
A contact wrench describes forces and moments transmitted through support. PRIME demonstrates physically consistent reconstruction of frictional contact forces from robot dynamics. [2] The remaining friction margin determines how much tangential demand can be added before slip.
Slip Starts Before Contact Is Lost
Incipient slip provides warning before gross sliding. Tactile research shows local contact patterns can reveal this transition. [4] Dense data protocols improve learned tactile slip detection across contact conditions. [5]
The Whole Body Creates Redundancy
In multicontact behavior, feet, hands, forearms or other surfaces can share support. Whole-body tactile interaction research demonstrates real-time extraction of contact information and its use in humanoid control. [3] If one contact degrades, force can migrate toward contacts with better evidence and margin.
Confidence Depends on Observability
A contact may be real but poorly observable. Contact observability depends on sensor placement, model quality, excitation and timing. Motor current can suggest external torque; joint position reveals kinematic consistency; IMUs reveal body response; tactile arrays provide local evidence.
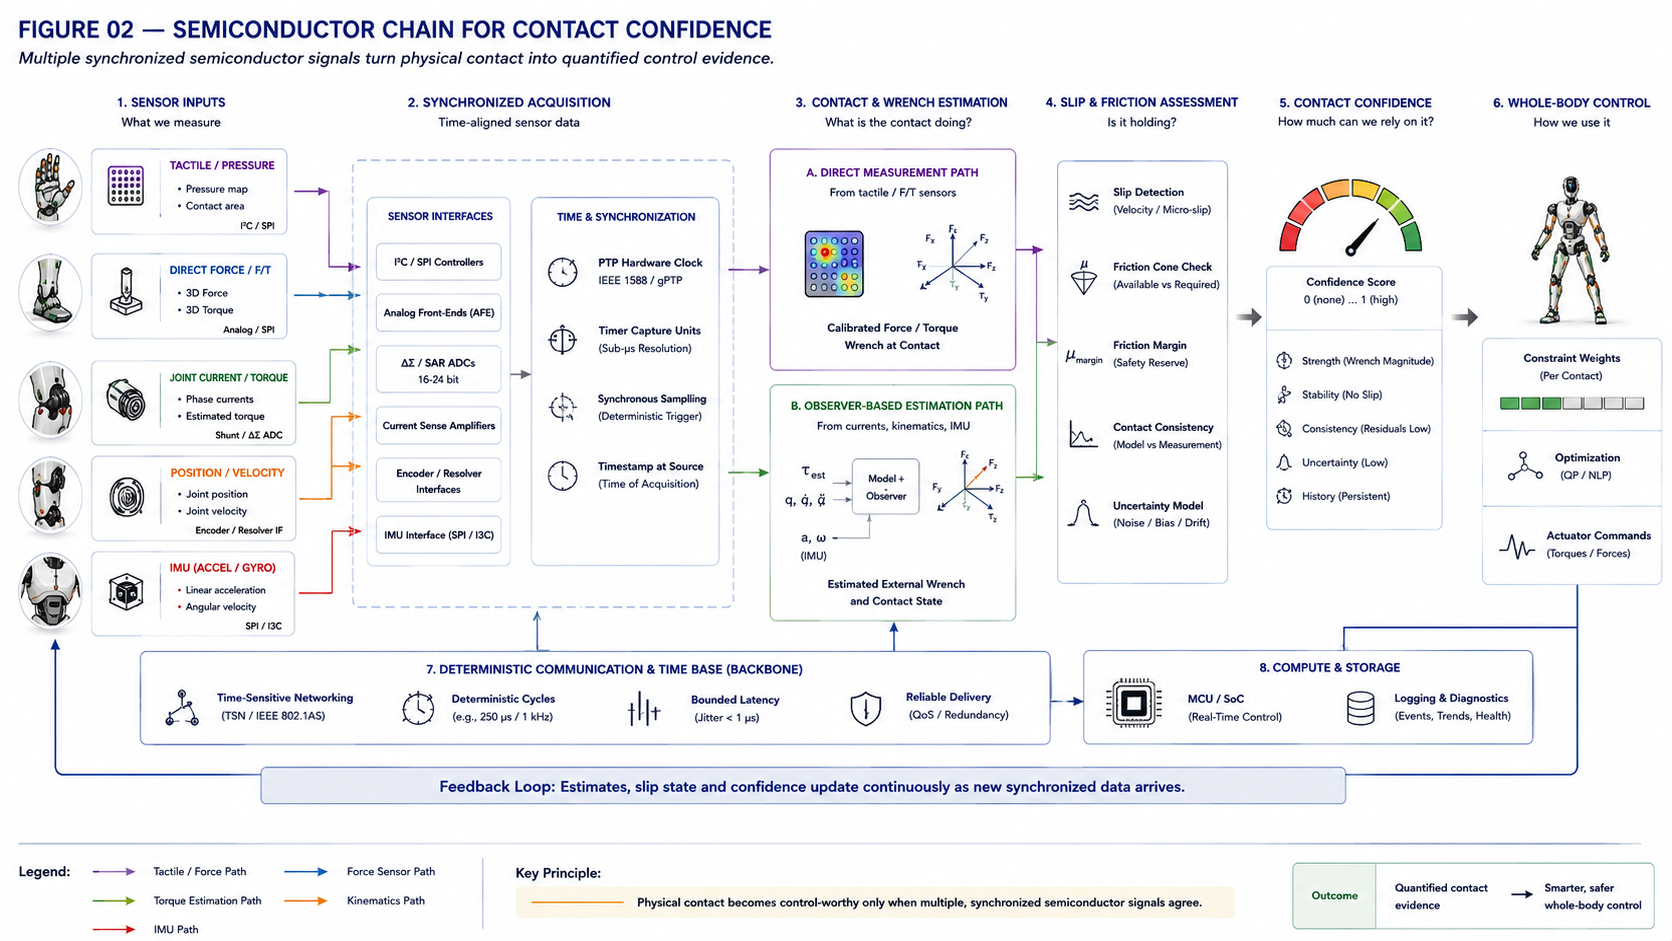
The Semiconductor Control Chain
Contact confidence begins in synchronized acquisition. Tactile and force interfaces, motor-current sensing, position feedback and inertial sensors must describe approximately the same physical event. Deterministic communication and timestamps preserve temporal relationships. Real-time estimation converts evidence into contact state, wrench, slip risk and confidence before whole-body control allocates torque.
Saturation Is Different from Failure
A contact can remain present while reaching contact saturation. Required tangential force may approach friction limits, or normal force may approach structural limits. Confidence should therefore represent usable authority, not merely detection probability.
Control Should Degrade Reliance Smoothly
Binary contact logic creates abrupt transitions. Confidence-weighted control can progressively shift force, shorten steps, slow manipulation, add hand support or initiate recovery. When confidence falls below validated limits, the robot must select another physical strategy.
Conclusion
Physical AI acts through contacts, and every contact is uncertain. Robust humanoids need a control abstraction joining tactile evidence, force estimation, dynamics, friction and timing into a continuously updated statement of trust. Contact confidence makes that statement actionable.
References
- IEEE AMC. Estimation-based Control of Forces Applied to Parts of Humanoids That Do Not Have Force Sensors. 2026. https://ieeexplore.ieee.org/
- Kang et al.. PRIME: Physically-consistent Robotic Inertial and Motion Estimation for Legged and Humanoid Robots. 2026. https://arxiv.org/
- Armleder et al.. Real-Time Control of a Humanoid Robot for Whole-Body Tactile Interaction. 2025. https://arxiv.org/
- Zhao et al.. Universal slip detection of robotic hand with tactile sensing. 2025. https://doi.org/
- Zenha et al.. Let’s DENSE: a novel protocol for efficiently collecting dense and diverse data for tactile slip detection in robotic grasping. 2025. https://arxiv.org/